Locations:
Despite technological development addressed to ocean-monitoring has been significantly improved during the last two decades with new platforms, sensors and telemetry systems, there are still many unsolved gaps in terms of data quality, reliability, efficiency and sustainability. Ocean glider technology (including autonomous underwater and surface vehicles) offers a new approach in terms of monitoring capacity and sustainability, enabling to perform observations in spatiotemporal scales hitherto unavailable.
PLOCAN Glider School is a hands-on ocean-glider technology and training forum mainly addressed to ocean-glider technologies and their wide range of monitoring applications learning. Students and professionals from marine and maritime fields interested in learning about this specific and emerging autonomous ocean vehicle technology are truly welcome to join in. The PLOCAN Glider School is a training action promoted by PLOCAN in line with international programs and projects such OceanGliders, EuroGOOS, AQUARIUS, among others, that provides a state-of-the-art overview and the operational basis approach to this technology through theoretical and practical teaching sessions in both wet-lab and open waters of Gran Canaria.
Leading corporate partners and key-reference research institutions across Europe and USA closely cooperate with the PLOCAN Glider School by teaching some of the didactical program contents, that includes as main topics (for each glider technology) a technology overview, nuts and bolts: how it works, mission setup and piloting, deployment and recovery in open waters, data management and applications, maintenance, etc.
The present work attempts to summarize the role and contribution summary of fifteen years of PLOCAN Glider School where more than two hundred-fifty attendees from thirty-six countries of the five continents have been trained, in addition to the support by twenty-eight leading companies (as technology developers in this field) and institutions (as leading operators and end-users), enabling new user groups and the international glider-community growth in support to initiatives such EOOS and GOOS aiming to a more efficient and sustainable global ocean-observing strategy based on this cutting-edge technology.
IMCA Diving 202-2027: What we've done and what we're going to do
Every operator in the offshore inspection space is managing the same set of constraints. Vessel day rates run $50,000 to $100,000. Mobilization takes weeks. The crew shortage is structural: BIMCO forecasts a 90,000-officer shortfall, DP certification takes two years per operator, and the ROV workforce is staffed to about 73% of demand. A $65 billion construction backlog is creating decades of new inspection obligations on top of existing requirements. Routine inspection that should happen on a regular cadence gets deferred, bundled, or skipped because the cost to mobilize is out of proportion to the scope.
This presentation argues that both the technology and the business model for offshore inspection are changing, and that the change matters for anyone who operates, manages, or contracts workboats for survey and inspection work.
Standard Subsea is building and operating these systems today. Scout is a 14-foot, all-electric uncrewed catamaran carrying hull-mounted sonar, USBL tracking, and an inspection-class ROV rated to 300 meters. It launches from a boat ramp on a standard trailer. Two operators pilot both vehicles from shore over Starlink. The system costs $500,000 to build fully loaded. The key technical development is a custom between-hull launch and recovery system that cycles an inspection-class ROV from an unmanned platform, closing the loop on complete inspection from shore with nobody on the water.
But building a cheaper vehicle does not change an industry if the procurement model stays the same. Today, every inspection job follows a rigid sequence: identify a need, scope a project, solicit bids, award a contract, wait weeks for mobilization, execute the campaign, demobilize, wait for the report. That process exists because the assets are expensive and scarce, so every engagement has to justify itself as a standalone project. Standard Subsea is replacing that entire workflow. Credit-based pricing where a day of inspection, vessel, ROV, operator, data processing, and deliverables, is a published line item. No RFPs. No six-figure scoping exercises. Same-week turnaround. An inspection campaign becomes a series of service calls that customers budget as a recurring operational expense.
When you remove the procurement friction alongside the mobilization cost, the calculus around inspection changes. Pipeline operators running GVI and CVI on aging infrastructure get faster inspection cycles and earlier visibility into integrity issues. Port authorities survey seabed and structures without shutting down berths for a crewed vessel. Decommissioning campaigns get pre-decom baselines, monitoring during removal, and post-decom clearance from one asset instead of scheduling separate charters for each phase. Mooring inspections that get deferred because a two-day job cannot justify a full mobilization actually get done. The same annual budget that bought one inspection campaign from a crewed vessel buys five.
The long-term vision is not a tool. It is an operating system. Regional hubs permanently positioned near concentrations of offshore infrastructure, where operators book inspection the way they book any recurring service. Over time, compliance calendars get built around hub availability. Maintenance budgets get structured around published pricing. Annual inspection plans assume same-week turnaround instead of six-week mobilization windows. Every mission generates operational data that compounds into predictive maintenance baselines and digital twin datasets, which means inspection shifts from verifying what went wrong to anticipating what will. The customer's entire planning apparatus reorganizes around the hub, and once that happens, the value is no longer in any single vehicle. It is in the fact that everything around it has been redesigned to assume it is there.
That model does not replace crewed vessels across all offshore work. It replaces them for routine, repeatable inspection, freeing crewed assets and qualified crew for the complex jobs that actually require them.
By December 2026, Standard Subsea will have completed five commercial programs across three continents: cable pre-survey off California, port infrastructure survey in the Great Lakes, pipeline and jacket inspection in the Gulf of Suez, cable route survey in the South Pacific, and a public sector coastal security survey in U.S. waters. This presentation draws on those programs to cover the technology, the business model, the per-day economics, and where this class of system reaches its limits.
The rapid growth of offshore renewable energy, subsea infrastructure, autonomous systems, and ocean technology is creating significant demand for a highly skilled underwater workforce. At the same time, employers face persistent shortages of qualified technicians, engineers, ROV operators, and marine professionals with the competencies needed to support increasingly complex operations. Addressing this challenge requires innovative workforce development models that connect education, industry, and government.
This presentation highlights the Fisheries and Marine Institute of Memorial University of Newfoundland as a case study in building a responsive workforce ecosystem for the blue economy. Through industry-informed academic programs, applied research, customized training, and work-integrated learning, the Marine Institute prepares graduates and professionals for careers in underwater operations, marine engineering, ocean mapping, autonomous systems, and offshore industries.
The presentation examines how competency-based education, stackable credentials, experiential learning, and strong industry partnerships ensure that training remains aligned with evolving workforce needs. It will also explore strategies to increase participation by engaging veterans, women, Indigenous learners, career changers, and students from coastal communities, creating more inclusive pathways into marine careers.
Participants will gain practical insights into developing sustainable education-to-employment pipelines that support workforce readiness, innovation, and economic growth. By demonstrating how collaboration among academia, industry, and government can address critical skills shortages, this session provides a model for preparing the next generation of professionals to support safe, resilient, and technology-driven underwater operations throughout the global blue economy.
Orpheus Ocean builds and operates ultra-scalable autonomous underwater vehicles for deep ocean and seabed data collection. In this talk we begin with an overview of the capabilities and novel design philosophy behind the Orpheus AUV, which enables high resolution benthic survey, sample retrieval, and long duration monitoring, in a single agile platform. The Orpheus AUV is intended primarily to automate and scale seafloor work typically performed by ROVs, and can be deployed from small vessels of opportunity. We review results from recent deployments, including deep exploration with NOAA at >5,000m, and exercises with the DoW. Data, results, and learnings from deployment of the prototype vehicles will be shared. Finally, we discuss the potential applications of the Orpheus approach to various mature and emerging industries including seabed minerals, subsea infrastructure, and defense.
Twenty-four nautical miles off San Francisco, California, Open Ocean Robotics, as part of Team @Orchard, is maintaining continuous observations at NOAA National Data Buoy Center Station 46012 without a moored buoy or permanent shoreside infrastructure. Since January 2026, the service has combined rotating solar-powered uncrewed surface vehicles (USVs), remote fleet operations, and local support for launch, recovery and shoreside servicing.
The DataXplorer USVs use controlled station-keeping to collect wind, atmospheric and surface-ocean measurements. Hourly datasets are transmitted through redundant cellular and satellite communications for NOAA quality-control and dissemination workflows.
Continuity is achieved by rotating USVs between the offshore station and shore. While one vehicle remains on station under Open Ocean Robotics’ control, another can be recovered, inspected, serviced and recharged by the local operator. This model reduces reliance on specialized vessels, permanent field crews, and travel by technical personnel.
A field-deployed solar charging trailer provides independent shoreside power, battery storage and connectivity at a location without conventional marine or electrical infrastructure. This capability supports year-round service during periods when onboard solar generation cannot sustain continuous operation by a single vehicle.
The presentation will share practical lessons in fleet rotation, remote vehicle and sensor monitoring, local-operator coordination, energy management, launch and recovery, preventative maintenance, and continuity of data delivery.
This operating model reframes persistence: the measure is not how long one vehicle remains at sea, but how reliably the overall system delivers uninterrupted observations. The approach could also support persistent surface gateways for seabed instruments, underwater vehicles, and acoustic sensor networks in remote coastal, offshore and northern environments where permanent infrastructure and frequent specialist-vessel visits are impractical.
Lessons from other energy sectors show that workforce constraints can slow deployment and delay commercialization, even when the technology is ready. Without a skilled workforce in place, progress stalls.
The marine energy sector is no different; its growth depends on a workforce prepared for both engineering and offshore operations. The question is: Are we preparing the marine energy workforce fast enough to meet projected industry demand?
To better understand workforce readiness and identify critical gaps, the National Laboratory of the Rockies (NLR), with support from the U.S. Department of Energy’s Hydropower and Hydrokinetic Office (H2O), conducted a marine energy workforce assessment in 2024.
Building off a 2019 baseline assessment, this study integrates data from educational institutions and industry stakeholders to provide a comprehensive, system-level analysis. NLR applied a mixed-methods approach to characterize the availability of marine energy curricula, trainings, and field-based learning, and assess industry workforce preparedness. This included:
Key findings from the education assessment
Findings show that dedicated marine energy programs remain limited. Among the surveyed institutions, only one reported an associate degree, three reported undergraduate degrees, and two reported graduate-level programs explicitly focused on marine energy. More commonly, marine energy content was embedded within mechanical engineering, ocean engineering, or environmental science curricula.
While 56% of responding schools incorporated some coverage of marine energy topics, sustained programming was constrained by inconsistent funding streams, limited dedicated faculty, and low course enrollment. Institutions with access to field deployments, specialized facilities, or competitions (e.g., the Marine Energy Collegiate Competition) reported higher levels of student engagement and retention.
Key findings from the industry assessment
Industry perspectives reinforce the need for workers in the near future (58% of respondents plan to increase staff in the next 5-10 years) and interdisciplinary skillsets, combining core engineering competencies and maritime operational experience with commercialization and business acumen. Employers report persistent challenges in recruiting candidates who combine technical expertise with practical, field-based or offshore experience in safety-critical environments.
These workforce gaps mirror challenges seen in subsea operations, offshore construction, and marine robotics, where field experience and safety-critical skills are essential.
In response, with H2O's support, NLR is implementing workforce development strategies to strengthen the workforce pipeline, including experiential learning models (student competitions), career pathway tools (e.g. the Marine Energy Career Map), and pilot fellowship programs.
These findings highlight a need for training models that better integrate classroom learning with hands-on, field-based experience, as well as opportunities to transition skilled workers from adjacent maritime, offshore, and subsea industries into marine energy roles.
What to expect
This presentation will:
In addition, NLR has conducted longitudinal student surveys since 2020 s to track how student perceptions of marine energy viability and careers have changed over time.
This session will provide attendees with actionable insights into workforce gaps, training needs, and strategies that can support deployment and reduce workforce-related bottlenecks across marine and offshore industries. By sharing research findings with UI attendees, NLR aims to exchange best practices and bring together the stakeholders across the offshore community to discuss shared challenges and needs.
An in-depth review of the current U.S. Subsea Vessel Fleet, the impact of recent consolidation developments between vessel owners and contractors, a shift in focus towards more DSVs, and some comparables with other regions worldwide.
The recent consolidation between Hornbeck and Helix, Saipem and Subsea 7, the acquisition of Harvey Gulf Subsea fleet by Otto Candies, and a raft of M & A activity by Chouest, has significantly shaken up the U.S. subsea vessel landscape. What impact will such consolidation have on the market in the short and long-term for Charterers and end clients? What comparables can we draw with the North Sea and other regions? What are some of the barriers to newbuild vessels in the offshore market and how can these be overcome? What impact has the rise and fall of the offshore wind market had on the U.S. subsea fleet?
The Saturation Diving Market in the U.S. has been dominated by a very small number of players and vessels yet it has seen a recent increase in activity from new entrants and converted vessels for this market - is the market ready for more players and what is driving this renewed interest?
As the blue economy expands across offshore energy, coastal engineering, emergency preparedness, and maritime technology, employers face a growing workforce gap. The Advanced Research & Innovation Institute (ARII) has developed a 9-month workforce model designed for young adults ages 18–24 that combines six months of hands-on academic training with a three-month paid internship placement with industry partners.
This session will explore the development of ARII’s Coastal Academy, including curriculum design, industry alignment, small-cohort training, and measurable workforce outcomes. Attendees will gain insight into building regional workforce pipelines, securing industry partnerships, and aligning training programs with emerging coastal and offshore technologies.
The session will also highlight lessons learned from designing and deploying Massachusetts’ first nearshore sensor network and how applied research can directly support workforce development.
Underwater robotics, aquaculture monitoring, and subsea inspection are increasingly driven by AI and machine vision, but most systems still rely on imaging hardware that was never designed for operation in water. We’ll walk through a comparative optical study showing how common subsea camera architectures perform — from flat and dome ports to corrector optics — and contrast those with purpose-built wet lens designs. The takeaway is not just better images are possible, but more reliable perception, lower downstream compute requirements, and better real-world AI performance are possible even in challenging underwater environments.
Underwater imaging often relies on adapting terrestrial camera lenses for subsea use through flat or domed optical ports. While convenient and cost-effective, these configurations introduce optical compromises due to refractive index mismatches at the air-glass-water interface and lens designs optimized for in-air use. This talk presents a comparative performance analysis of several underwater port configurations, including flat ports, hemispherical domes, Ivanoff-Rebikoff correctors, and a multi-element custom "wet" port, alongside a fully customized underwater lens system explicitly designed for direct operation in seawater.
Optical metrics, including modulation transfer function (MTF), lateral chromatic aberration, field of view (FOV), and image simulation fidelity, are evaluated. Results show that terrestrial lenses with port adaptors suffer significant degradation in image quality, while Ivanoff-Rebikoff correctors recover resolution but leave residual chromatic and geometric distortions. The Optopax custom port further improves performance, while the fully customized underwater lens surpasses all configurations, delivering superior MTF, complete chromatic correction, and field preservation, along with form factor flexibility for integration into space-constrained platforms.
Simulated Siemens star charts and real-world scenes demonstrate significantly enhanced edge definition, spatial detail, and color accuracy with both the custom port and the bespoke wet lens. By eliminating the optical discontinuities at air-glass interfaces and leveraging seawater as an active optical medium, the fully customized design represents a new design strategy in subsea optics, enabling high-fidelity imaging for underwater robotics, aquaculture monitoring, and AI-enhanced marine vision applications.
A revolution in offshore survey and inspection is accelerating. Autonomous systems, long-promised to replace crewed survey vessels, and their cost, are reaching a level of maturity where this reality is now within sight.
However, challenges remain to fully decouple from crewed vessels. Today, most AUVs still need to be launched and recovered from a crewed vessel. These exquisite systems command a high day-rate and haven't repeatably proven that they reduce enough ship days-at-sea to justify the cost.
Ulysses is working to address these challenges in two ways: by building the lowest-cost platforms in their class and the ability to autonomously launch-and-recover multiple systems from a single uncrewed vessel. Through this approach, Ulysses will achieve a step-change, unlocking a truly cost-effective approach to persistent data collection and monitoring of subsea assets.
Learn how a high school ROV team from rural Michigan conducted an ROV workshop in the Dominican Republic.
The Stockbridge Jr/Sr High School ROV was invited to conduct research, test equipment and conduct an educational outreach project in the Dominican Republic, February 23 to March 1, 2026.
The procets aimed to Inspire, Engage, and Educate students while providing a unique research experience in the Caribbean Islands. The project had three main goals; (1) to connect with a school in the Dominican Republic to share knowledge and culture between students, and conduct a STEM program. (2) to conduct an ROV Workshop for a STEM class at the Punta Cana International School. (3) to donduct ocean and reef monitoring off the coast of the Dominican Republic.
Operators in the renewable energy and oil and gas industries rely upon Controlled Flow Excavation (CFE) technology to support complex scopes – with the triad of ever-greater performance, efficiency and environmental impact driving continual development.
With more than 640 successful CFE projects to our name worldwide, James Fisher has over 25 years of practical experience in safe, efficient, non-contact seabed intervention. James Fisher introduces JetFlow 100 as the next generation of CFE technology, designed to overcome increasingly challenging soil conditions while maintaining efficiency and cost-effectiveness.
JetFlow 100 is versatile, with a compact footprint and high excavation performance enabling a variety of inspection, maintenance, repair, and commissioning and decommissioning activities across the oil and gas and renewable energy industries. Uses include both pre- and post-installation trenching of pipelines, umbilicals, and subsea infrastructure, or seabed deburial to support structure inspection or decommissioning activities.
JetFlow 100 is a step change in subsea excavation capability. By significantly increasing flow power and jetting efficiency, the system enables effective excavation in stiffer soils and clays—conditions where conventional CFE tools have historically struggled. This optimal balance between mass flow rate and velocity is achieved without needing to add large, high-pressure jetting spreads, thereby reducing vessel deck space requirements and contributing to lower overall project costs.
James Fisher has combined the key advantages of non-contact excavation with the capability to operate across a wide range of soil strengths – including clays up to ~100 kPa - in standard configuration.
This ensures minimal risk to subsea assets while delivering consistent, repeatable trenching performance, and expands the applicability of CFE methods into projects that would traditionally require more complex, resource-intensive solutions.
The system has undergone successful testing in Aberdeen, UK, demonstrating stability and performance across a range of operating conditions without compromising tool integrity. These results validate the design philosophy of enhancing excavation power while maintaining operational simplicity and reliability, with JetFlow 100 now available to customers throughout the Americas.
This paper will present the development journey of JetFlow 100, including design innovations, testing and simulation results, and its potential to re-establish CFE as a preferred methodology in subsea project planning. The discussion will also explore how this technology can unlock efficiencies in future offshore operations by reducing cost, complexity, and environmental impact, both in North American waters and beyond.
James Fisher is running an advanced simulation programme to de-risk and optimise the design of our CFE tools such as the JetFlow 100, and to demonstrate their effectiveness. We are investing in sophisticated simulation tools and developing cutting-edge simulation techniques to perform simulations and ensure simulation results are representative of real life.
With rigorous simulations and testing underway throughout the year, additional data will be shared at Underwater Intervention in December 2026.
Autonomous subsea vehicles are evolving beyond discrete mission tools into integrated operational systems. Among the most promising developments is the emergence of port‑launched, long‑range unmanned underwater vehicles (LUUVs) designed to deliver persistent, lower‑logistics subsea survey and infrastructure awareness without reliance on vessel‑intensive operations.
This presentation explores how advances in vehicle architecture, endurance, navigation, and onboard edge processing are enabling a new operational model for autonomous survey. By exploiting data at the point of collection and integrating persistent data workflows, these systems reduce time to insight while expanding coverage and operational flexibility.
Topics include the design considerations of long‑range autonomous platforms, navigation and sensing strategies, onboard data exploitation, and how repeatable autonomous missions create compounding value through continuous infrastructure awareness. The session will also examine representative operational concepts—ranging from completed activities to near‑term deployments—to illustrate how port‑launched autonomy can support scalable survey operations across offshore and coastal domains.
Ultimately, the presentation positions autonomous UUVs not as standalone vehicles, but as system‑level enablers—reducing logistics, increasing persistence, and making subsea survey and monitoring more economically and operationally practical for a broader range of users.
The MATE Floats Marine Technology Summer Workshop is an advanced, immersive, multi-day learning experience around float technology, sensors, programming, and data science. Hosted by the University of Washington's (UW) School of Oceanography, the goal of this five-day workshop is to provide students with 1) the opportunity to learn about and experience marine technologies first-hand and 2) to develop and build upon the skills they will need for success in the technical workplace.
The target audience is two-year community and technical colleges students from across the U.S. Community and technical colleges serve diverse populations; students at these institutions are less likely to have access to these opportunities, which makes programs like MATE Floats critical to increasing and diversifying the potential talent pool prepared to enter the marine technical workforce.
This presentation will include an overview of the workshop. Student participants will also present information about their workshop experience, including a shipboard experience on the UW's R/V Rachel Carson, skills gained, and the data science project completed during the workshop.
MATE Floats is funded by two National Science Foundation-funded projects; the National Center of Autonomous Technologies and the Global Ocean Biogeochemistry (float) Array (the Monterey Bay Aquarium Research Institute is the lead on the GO-BGC project). MATE Floats is one of several summer workshop opportunities presented by the Marine Technology Society.
The highest-risk portion of subsea cable infrastructure receives the least attention. The coastal band within the first 200 feet of water accounts for roughly 15–20% of total installed mileage but a disproportionate share of recorded failures. Large DP2 vessels are too costly to deploy in these depths, while small coastal craft lack the endurance and sensor payload for high-quality inspection. This gap leaves a critical portion of the global network effectively invisible and forces operators into reactive maintenance rather than proactive monitoring.
This presentation introduces a new approach to shallow-water survey using remotely operated surface vessels. Scout-18, an 18-foot unmanned platform paired with a tethered ROV, replicates the core functions of an 80-meter survey ship at a fraction of the cost. The system captures video and sonar data that feeds into a software platform converting raw survey logs into continuously updated digital twins, with automated anomaly detection and integration into existing GIS and ERP systems.
We will share early findings from engagements with cable owners off the coast of California, pipeline monitoring in Egypt, and cable routing work in Vanuatu. These case studies illustrate how collapsing the unit economics of inspection enables asset owners to shift from reactive fault response to continuous situational awareness.
Attendees will gain insight into the operational and technical considerations of deploying compact unmanned survey systems in shallow water, the data workflows required to translate raw survey output into actionable intelligence, and the implications for cable protection strategies in high-risk coastal zones.
SeaTrac and the University of Southern Mississippi are working together to demonstrate the use of SeaTrac’s SP-48 uncrewed surface vessel as a persistent surface expression for uncrewed underwater vehicles, subsea sensors, and other underwater assets. The demonstration will evaluate how a low-logistics, long-endurance USV can support subsea operations by providing remote positioning, command-and-control support, and communications relay capabilities using an integrated Sonardyne Gyro USBL 5000 system.
Subsea operations increasingly depend on distributed underwater systems, including UUVs, seabed instruments, acoustic modems, and other autonomous or remotely monitored assets. These systems often require a surface node to provide acoustic positioning, data relay, mission coordination, and operator awareness. Traditionally, this role has been filled by crewed vessels, which can introduce significant cost, scheduling, endurance, and personnel-risk constraints. The SP-48 demonstration is intended to show how an uncrewed maritime system can assume many of these surface-support functions while reducing operational burden and enabling more persistent subsea presence.
The SP-48 is a 4.8-meter, solar-powered USV designed for persistent operations from nearshore environments to open ocean. It supports 24/7 operations, redundant communications, man-in/on-the-loop remote supervision, waypoint-based mission execution, AIS, 360-degree situational-awareness cameras, and multiple payload configurations. SeaTrac has previously operated the SP-48 on long-duration missions exceeding two months and 1,600 nautical miles, and has demonstrated acoustic payload operations, including a Gulf of Mexico data-harvest mission using a Sonardyne HPT 7000 payload to collect data from nine seafloor sensors over approximately 570 nautical miles.
For the proposed demonstration, the SP-48 will be configured to act as a mobile and persistent surface node for underwater assets. The system concept includes the Sonardyne Gyro USBL 5000 for acoustic tracking and positioning; onboard communications links to move vehicle, payload, and mission data ashore; and remote supervision from SeaTrac’s operations architecture. The University of Southern Mississippi team will lead test planning, evaluation, and demonstration activities, with SeaTrac supporting platform integration, operations, and mission execution. The work will assess how the integrated system performs as a surface expression for UUVs and other underwater assets, including its ability to support acoustic positioning, relay operational data, maintain mission awareness, and coordinate with shore-based operators.
This presentation will provide an overview of the demonstration objectives, system architecture, planned test approach, and results available at the time of Underwater Intervention 2026. It will discuss the operational value of using uncrewed surface vessels to support subsea work, including reduced dependence on crewed vessels, increased endurance, lower logistics, persistent access to remote operating areas, and the ability to scale support for distributed underwater systems. The presentation will also address practical considerations such as payload integration, remote operations, communications paths, safety and recovery planning, and coordination between USV operators and subsea mission teams.
The broader intent of this effort is to demonstrate that uncrewed maritime systems such as the SP-48 can provide a reliable, cost-effective, and scalable surface-support layer for subsea operations. By combining persistent USV operations with proven acoustic positioning and communications technologies, the demonstration will show a pathway toward more efficient support of UUV missions, subsea infrastructure monitoring, seafloor sensor networks, environmental data collection, and future offshore intervention activities.
The blue economy depends on a steady pipeline of skilled and connected ocean professionals, yet many students and early-career ocean professionals (ECOPs) struggle to break into the field (and stay in it) without structured support. The Marine Technology Society's (MTS) EMERGE program was built to close that gap.
EMERGE is a yearlong professional development and mentorship program pairing students and ECOPs with experienced industry mentors, providing monthly Career Accelerator Webinars, and culminating in fully supported, guided attendance at Underwater Intervention.
This presentation will share what MTS has learned across multiple EMERGE cohorts: which program elements most effectively build career confidence and professional networks, how mentorship accelerates participants' ability to navigate the industry, and what outcomes participants report in terms of career readiness, community connection, and long-term engagement with marine technology.
Layered Media Detection (LMD) represents a significant advancement in hydrographic surveying by extending the capabilities of multibeam sonar into environments where surveyors have traditionally relied on dual-frequency single beam echo sounders to assess fluid mud and layered sediment conditions. For decades, determining the extent and characteristics of fluid mud deposits has largely been a profile-based exercise, requiring surveyors to collect individual cross-sections and interpolate conditions between widely spaced survey lines. While effective for identifying sediment layers along a track line, these methods provide only a limited view of highly dynamic environments and often leave uncertainty regarding the spatial extent, thickness, and variability of sediment deposits between measurements.
Recent advances in broadband multibeam sonar processing have enabled a different approach. Layered Media Detection utilizes simultaneous multi-frequency acoustic analysis to identify and map multiple sediment interfaces during a single survey, allowing fluid mud and underlying sediment structures to be visualized as continuous three-dimensional surfaces rather than isolated profiles. This transition from line-based observations to full-coverage spatial mapping provides hydrographers, port authorities, and dredging organizations with a much more complete understanding of sediment conditions across an entire project area.
By producing co-registered datasets that reveal both upper sediment boundaries and deeper sediment structures, LMD enables the creation of detailed 3D models that illustrate sediment distribution, thickness, morphology, and change over time. Features that may be difficult or impossible to identify between single beam survey lines can be visualized directly, providing improved awareness of sediment accumulation patterns, dredging impacts, depositional trends, and other processes that influence waterway management. The ability to observe these conditions across a complete survey area rather than along discrete transects represents a fundamental shift in how layered sediment environments can be characterized and understood.
As the technology has matured through extensive field testing and operational deployments in ports, rivers, navigation channels, and dredged waterways, new applications have continued to emerge. Beyond simply extending traditional survey methods, LMD is enabling surveyors to evaluate sediment systems in ways that were previously impractical using conventional techniques. The resulting datasets support more comprehensive analysis of fluid mud behavior, sediment transport, and seabed evolution while providing a richer framework for visualization, interpretation, and decision-making.
This presentation explores the evolution of Layered Media Detection from its initial development through its refinement into an operational technology and examines how full-coverage 3D sediment characterization is changing expectations for hydrographic surveying in layered sediment environments. Through examples drawn from recent field deployments, attendees will see how advances in multibeam sonar technology are transforming what was once a sparse, profile-based workflow into a comprehensive spatial mapping capability, opening new opportunities for understanding and managing complex underwater environments.
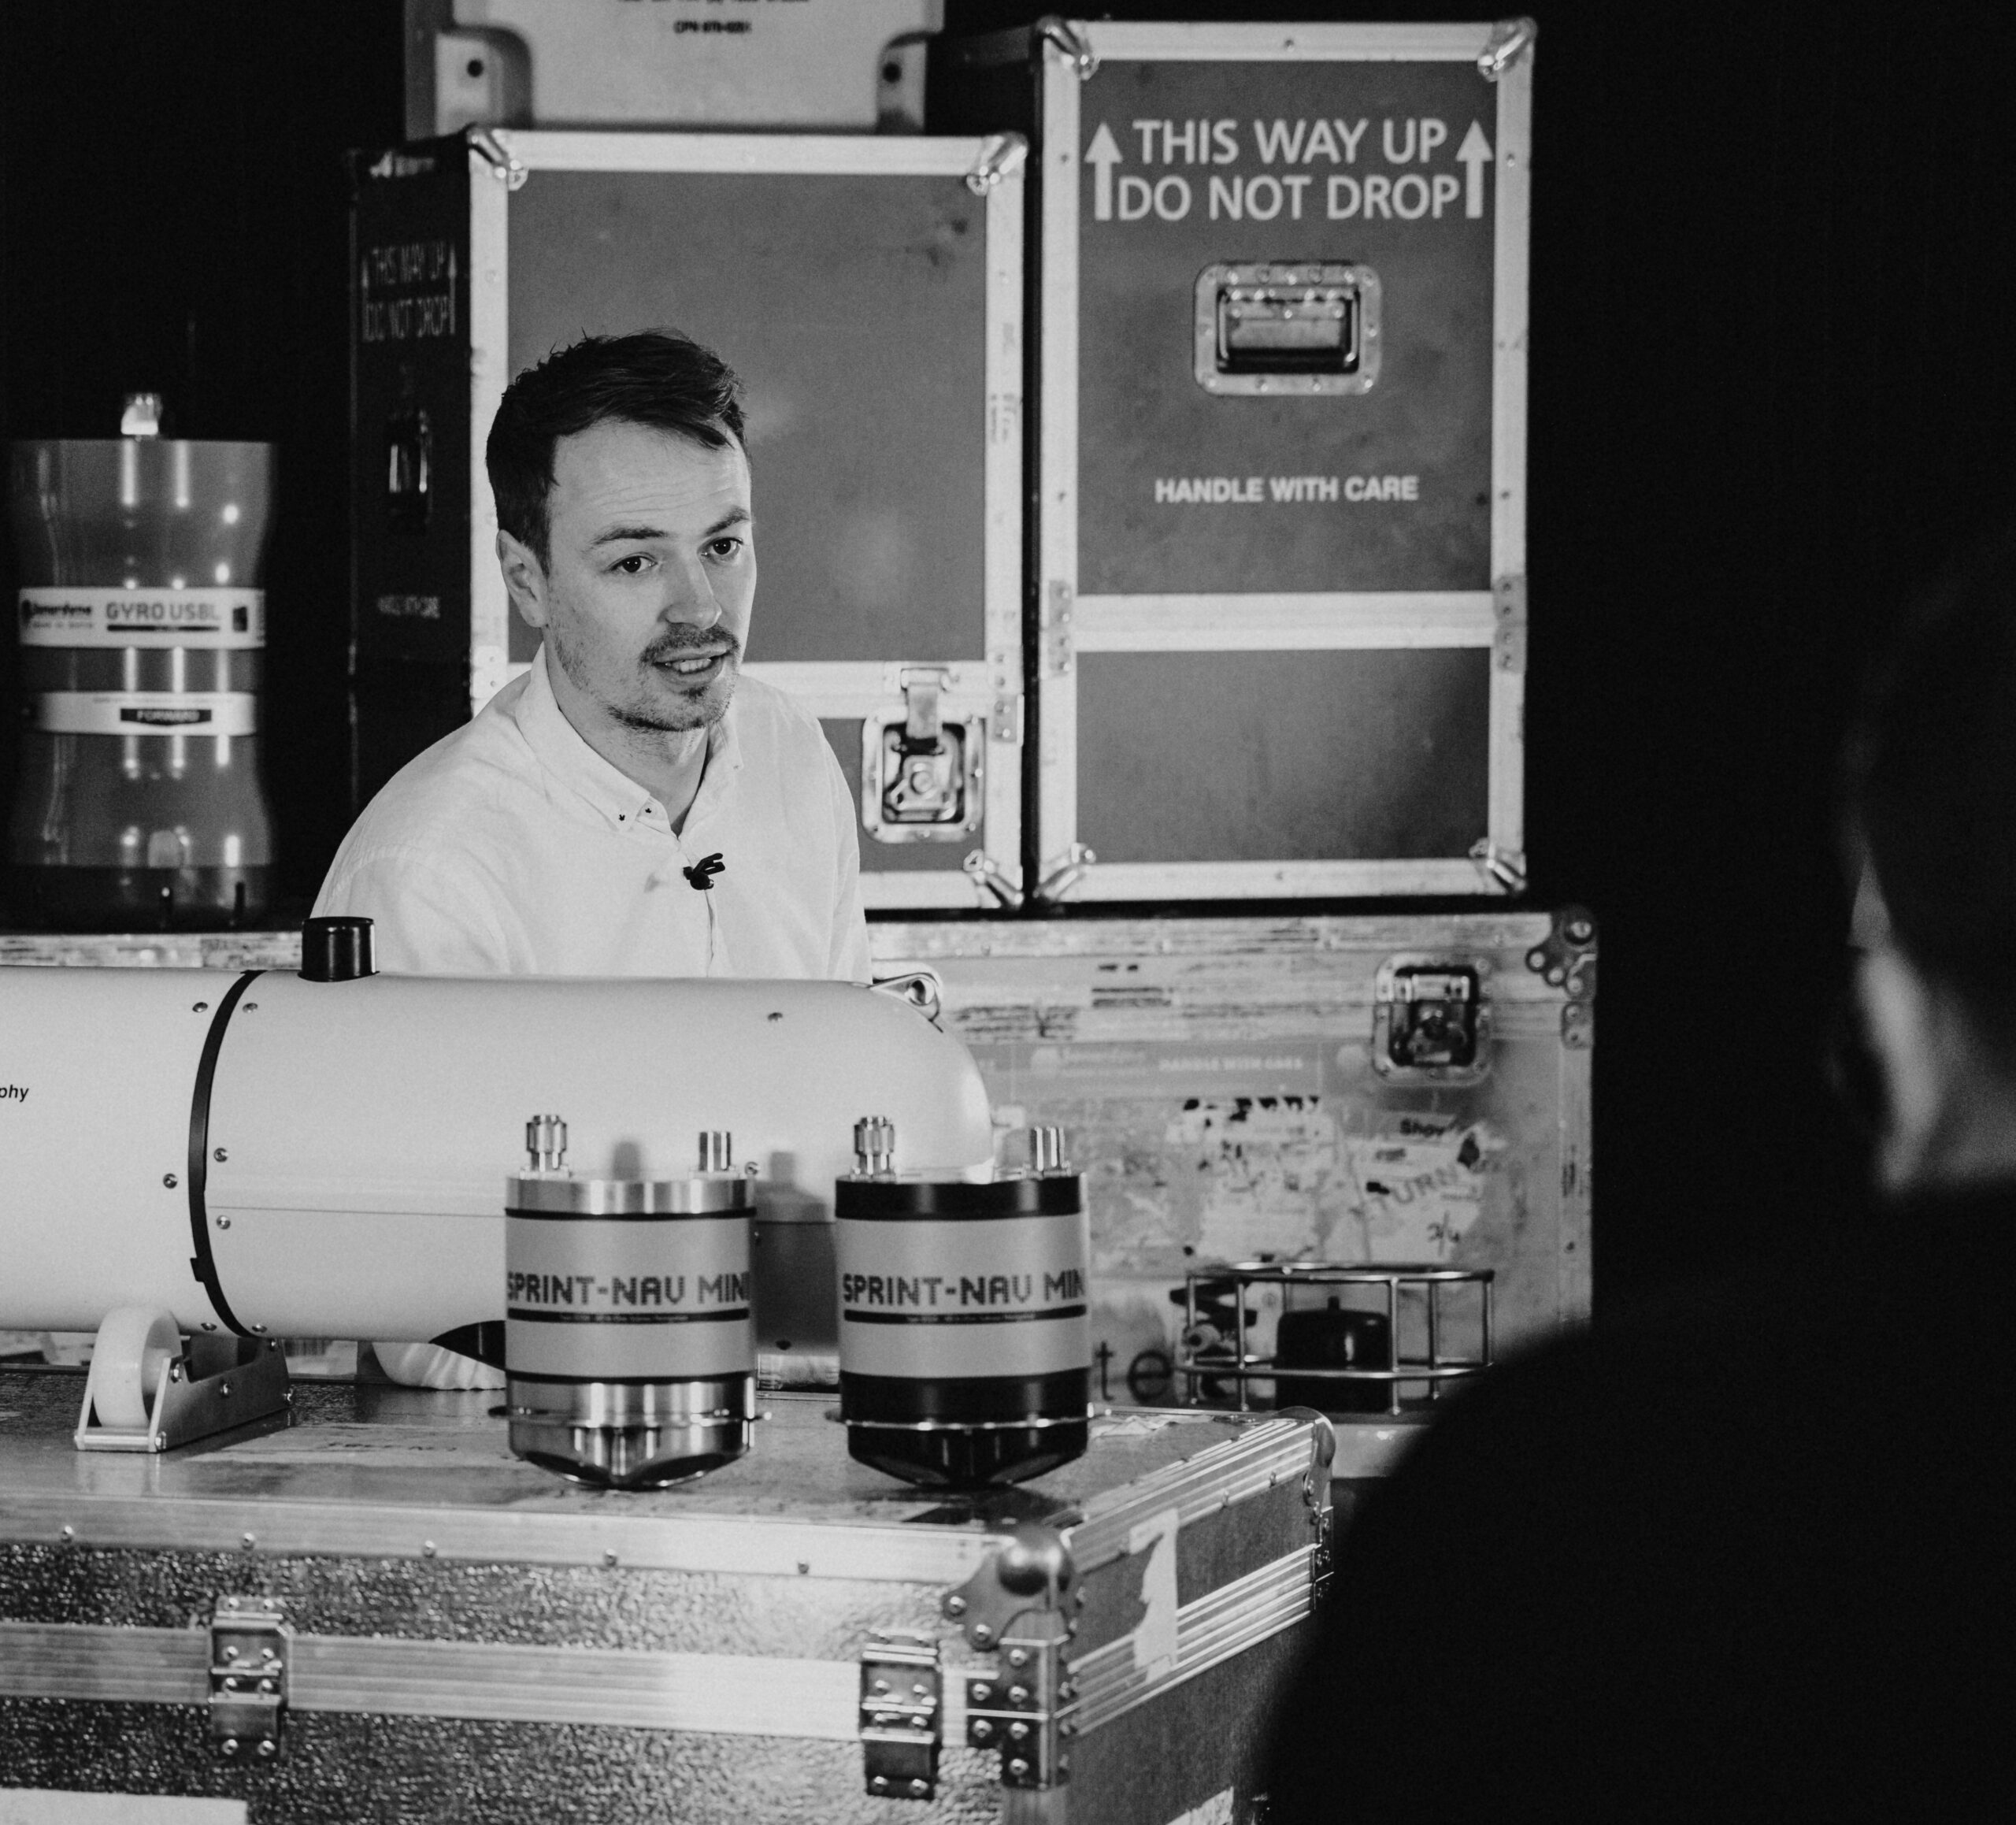
This paper presents an overview of the latest developments in Sonardyne’s SPRINT-Nav family. Throughout 2025 and 2026 the SPRINT-Nav family has undergone a significant update, from introducing the world’s smallest hybrid navigator that was presented at Underwater Intervention last year to a complete update across the rest of the family – SPRINT-Nav M, I, S and X and beyond. Through this presentation Sonardyne will highlight how we’ve evolved SPRINT-Nav to meet the increasing demands and use cases of complete suite of marine robotic platforms.
We will demonstrate real-world case studies of SPRINT-Nav performance with a focus on their impact on survey operations. Learn how the SPRINT-Nav family is enabling small inspection ROVs and micro AUVs to navigate and position to levels that enable them to take on tasks that previously called for larger and more capable platforms. Understand how uncrewed surface vessels can reduce their reliance on potentially spoofed or jammed GNSS aiding with SPRINT-Nav taking care of vehicle navigation in a GNSS independent solution. Discover how the new generation of ultra long range extra large UUVs can transit thousands of kilometres in mid deep water without the need to surface with a reliable and precise navigation payload onboard that means mission and data are solid.
Finally, the paper will explore how collaboration with industry partners is positioning SPRINT-Nav as a critical enabler of increasingly remote and autonomous operations. Through interoperability with complementary technologies and ongoing innovation, SPRINT-Nav supports the transition toward smarter, more autonomous subsea systems, reducing operational costs while maintaining mission critical requirements that in today’s operations still rely heavily on human intervention.
The offshore energy industry relies on accurate ocean current measurements to reduce risk and optimize exploration, development, and production operations, especially in the Gulf of America where assets frequently get exposed to the effects of the Loop Current System (LCS). The current industry standard for LC surveys utilizes a data acquisition system deployed aboard offshore supply vessels (OSVs) of 200 feet or greater. Recent technological advancements have made it possible to deploy a comparable data collection payload from a purpose-built autonomous vessel. The first successful LC survey was conducted in August 2025 using Chance Maritime’s new 40-foot Uncrewed Surface Vessel (USV) designed for long endurance in extreme ocean conditions. The platform demonstrated five days of fully autonomous operation, collecting data comparable to measurements from traditional OSV-based surveys and demonstrating sufficient accuracy for operational use. This system offers a viable path toward improved real-time ocean monitoring and offshore decision support.
A new system for underwater mechanical application (patent pending) of underwater antifoulants will be dislosed. It incorporates Barnacle-Blocker, LLC's crayon-like wax based antifoulants into a hook & loop (compare to Velcro) disk that attaches to a mechanical polisher. The disks can be used on inderwater compatible polishing disks operated manually or by robots to coat propellors and other underwater surfaces with an antifoulant.
Through participation in the MATE ROV Competition, students develop and advance technical as well as employability skills – skills that are critical to supporting and furthering companies and organizations contributing to the Blue Economy. Further, via substantive interactions with professionals from the workplace who volunteer as judges, mentors, and technical support, students are exposed to potential careers, expand their awareness of job opportunities, and gain insights into career pathways.
Students as well as employers share that listing MATE on a resume moves job candidates to the top of the pile. To further elevate and increase that visibility and recognition of the role that the MATE ROV Competition plays expediting career preparedness and workforce development, MATE is partnering with Oceaneering International, other industry players, and educational institutions to validate and formalize the achievement of the knowledge and skills gained through participation in MATE.
This presentation will provide additional context as well as details on the work and progress to date.
Deploying AI on underwater and maritime platforms sounds straightforward until you're actually doing it. Teams run into the same friction points: integrating sensors from different vendors, building custom middleware, managing data pipelines, and trying to run inference on hardware with no reliable cloud connection. Most of that work has nothing to do with the problem they're actually trying to solve.
This talk covers how edge-native AI is changing that equation in working commercial systems today. Drawing on real deployments with VideoRay for automated underwater inspection, OceanAero for maritime threat detection on autonomous surface vessels, and WESMAR for intelligent commercial fishing sonar, we walk through what these integrations looked like, what broke, and what made them work. All three teams used NEPI (Numurus Edge Platform Interface) to skip rebuilding the sensor connectivity, edge inference, and data pipeline layers from scratch, freeing them to focus on the actual application.
Attendees will leave with a practical framework for evaluating edge AI for their own systems and a clear-eyed look at where the real integration challenges sit.
Triton Systems, Inc. has developed an underwater hydraulic stud welder. It has been tested with US Navy divers at the Navy Experimental Diving Unit in Panama City, FL. It was developed under SBIR Phase I and II. Triton will give an overivew of the unit, the results from recent testing events, SBIR R&D experience developing a new technology, and its future plans for the technology.
While our industry continues to carry on best practices that have been handed down for decades, the upcoming generation of divers need to be taught not only skills but professionalism from the longstanding mentors among industry leaders. Best practices can only continue when they're adopted by the next generation, who also come with a new way of learning. By engaging a mentorship and growth mindset, companies that want to remain competitive as employers of new divers need to grow along with them in the perspective that the future of our industry needs.
Some underwater inspections demand more from the video record than simply proving a dive took place. For JF Brennan, clarity is essential to doing the work properly, documenting what was found, and delivering footage that can be reviewed and acted on after the dive is complete. This session will walk through two use cases where that need is especially clear: FERC-regulated hydropower dam inspections and nuclear inspections. In both environments, the limitations of analog-style underwater video become hard to ignore. When footage is unclear, difficult to retrieve, or harder to review, the burden carries forward into reporting, inspection acceptance, and next-step decisions. JF Brennan and Reach Systems will use these examples to explore the practical difference digital underwater video can make in demanding inspection workflows. In FERC-regulated hydropower dam inspections, footage may become part of engineering and regulatory review where the inspection record needs to hold up beyond the field team itself. In nuclear facilities, recurring inspection of high-value pumps leaves little room for unusable documentation, rejected inspections, or repeat effort caused by footage that is not clear or accessible enough the first time. For contractors, engineers, asset owners, and dive leaders, this session offers a concrete look at why digital clarity matters, where analog workflows fall short, and what stronger underwater video can change in the field and beyond.
Sound speed profiles derived from Argo float data underpin acoustic prediction, AUV mission planning, and GNSS-acoustic seafloor positioning — but no existing product tells you how well-constrained those profiles are at any given location and time. When an operator substitutes a climatological prior for an in-situ cast, they accept unquantified risk. If the underlying Argo coverage was sparse or stale for that region, there is currently no signal that the acoustic model or position estimate is degraded.
This presentation introduces an open-source Python library that fills that gap. The library performs spatiotemporal interpolation of Argo temperature and salinity profiles and delivers two outputs at every query point: a propagated uncertainty estimate that combines sensor precision, vertical interpolation error, and spatiotemporal support; and an observational support score W, a coverage indicator that is large where floats are dense and recent, and small where coverage is sparse. Both outputs are delivered at query time, alongside the T/S estimate itself.
Results are validated through replication of a published Bay of Bengal sound speed study. Interpolation-introduced uncertainty substantially exceeds sensor precision and is comparable in magnitude to observed surface temperature variability, confirming that coverage gaps produce errors large enough to matter operationally. A support-encoded visualization makes these gaps immediately legible: well-constrained regions appear vivid, sparse regions wash out.
The library is available at github.com/Calvinxc1/argo-data-interpolation and supports both EOS-80 and TEOS-10 sound speed formulations. The goal is a practitioner-facing tool: something an AUV operator or acoustic modeler can query against their mission area and get an honest answer about what the float network actually knows.
Commercial diving carries inherent risks including Delta-P, entanglement, contaminated water, equipment failure, decompression illness, and human factors. This presentation examines how risk manifests and is mitigated from three critical viewpoints: the diver (end user), the contractor (employer/operator), and the client/site owner.
From the diver’s perspective, the individual bears immediate physical exposure. Mitigation emphasizes personal accountability: maintaining medical fitness, actively participating in job hazard analyses and pre-dive briefings, exercising Stop Work Authority when conditions exceed safe limits, and adopting disciplined habits such as bailout readiness and accurate logging. A key principle is leaving personal risk tolerance at the door upon signing in — recreational judgments do not apply; operations must follow the company’s defined risk thresholds.
From the contractor’s perspective, the company defines and enforces acceptable risk levels. Responsibilities include assigning qualified personnel, conducting thorough risk assessments and dive plans, providing proper equipment and training, and maintaining a strong safety culture. Through onboarding, toolbox talks, and daily safety meetings, contractors must clearly communicate risk tolerance and ensure employees understand that personal shortcuts are unacceptable once on the job. Comprehensive documentation, including signed JHAs and dive logs, provides essential liability protection.
From the client/site owner’s perspective, risk is influenced through contractor selection, project timelines, and site information quality. Clients without in-house diving expertise can significantly reduce exposure by choosing ADCI audited contractors with proven safety records and adequate insurance. Providing complete hazard data upfront and allowing sufficient planning time further strengthens risk controls.
This presentation highlights how aligned perspectives, clear communication, and professional practices among the diver, contractor, and client create layered protection that enhances safety and reduces liability in commercial diving operations. Practical takeaways and a simple three-perspective checklist will be provided.
The traditional model for subsea validation is a primary friction point for the Blue Economy, characterized by high capital risk, lack of infrastructure and fragmented data/systems. This presentation introduces an emerging paradigm in maritime innovation: the persistent, instrumented subsea test range. By establishing a five-nautical-mile-square "experimental airspace" in the underwater domain, we solve the critical challenge of GPS-denied navigation and real-time telemetry. We will present on a real world facility at Plymouth Smart Sound in the UK as well as aspirations for the US and wider markets.
The core innovation lies in a distributed mesh of acoustic positioning and communication nodes that function as "seabed satellites”. This network enables seamless tracking, positioning, navigation and data transfer from subsea robotic platforms to a surface gateway (buoys, vessels, USVs), which utilize high-speed satellite broadband to reach a remote operations center. When integrated with real-time environmental sensors and digital twin management systems, the range creates a live situational picture that allows for the testing and validation of subsea vehicle behaviors such as AI/ML.
We will explore how this infrastructure model standardizes TRL progression for offshore energy, defense, and science. Attendees will learn how networked sensing can shift the industry from bespoke, high-cost prototypes to scalable, field proven and market ready autonomous systems. Innovation isn’t just about robots, its about data. This is a networked environment that allow them to fail fast, fail small and fail safely to learn faster!
With the currrent emphasis on renewable energy throughout the world, existing hydropower infrastructure is being called upon more than ever before. Many structures are in desperate need of repair, maintenance, retrofit, and upgrades to maintain/boost production and overall efficiency. Specifically, the higher head facilities tend to be in difficult to access locations well above sea level, which present unique challenges to maintain both dive safely and efficiency to complete the work.
The US Navy Revision 7 provides direction for conducting dives with enriched oxygen (Nitrox), incorporating surface decompression on oxygen (SurDO2), and adjustments for higher altitudes. However, combining all three dive methods can be challenging; as doing this isn’t clearly defined in the USN tables.
J.F. Brennan Company, Inc. (Brennan) had the opportunity to combine these dive methods on a 3-year project in the Wasatch Mountains of Utah. The project involved diving on a reservoir situated at over 5,400’, and water depths ranging from 55’ to 125’. Brennan, with support from various experts in the field, extrapolated dive profiles to execute the work in a safe and efficient manner; utilizing various breathing mediums, safety stops, and decompression tables to achieve success. We will share our combined experience, dive profile selection process, safety protocols , and successful results to better prepare divers for similar projects in the future.
Accurate, reliable heading is fundamental to marine and subsea navigation particularly in GNSS-denied environments. Existing solutions force a trade-off: optical gyros, such as Fibre Optic Gyros and Ring Laser Gyros, deliver high precision but are large, power-hungry, and expensive, while lower-cost alternatives, such as GNSS heading and magnetometers, are highly sensitive to signal vulnerabilities or environmental conditions.
This presentation introduces the first commercially available MEMS-based north-seeking gyrocompass, targeting a critical market gap. Using advanced MEMS technology and advanced algorithms, the system directly measures Earth’s rotation to determine true heading eliminating reliance on magnetic sensing or external aiding.
The SBG Systems gyrocompass achieves sub-degree heading accuracy with fast alignment, even while in motion. It does so with minimal SWaP-C (Size, Weight, Power and Cost) impact, operating at 3–5 W and weighing just 300–400 g. This is significantly smaller, lighter, and more efficient than traditional inertial systems such as optical or spinning-mass.
Rather than replacing survey-grade gyros, this technology expands access to true north-seeking capability. It enables reliable, always-available navigation for constrained platforms, including micro-AUVs, ROVs, USVs, and commercial vessels. MEMS gyrocompassing is a scalable, cost-effective solution poised to reshape heading systems for the next generation of autonomous marine operations.
The traditional view of decompression sickness (DCS) pathophysiology is that injuries occur due to bubbles formed from insoluble gas. However, the role of bubbles is obscure because asymptomatic blood-borne bubbles are often present. A growing body of evidence suggests that DCS is a systemic process that involves activation of white blood cells and so-called microparticles that carry inflammatory chemicals. A natural defense against the inflammatory microparticles is a protein called plasma gelsolin (pGSN). The level of pGSN in the blood stream drops as a consequence of diving and in animals, repletion of this protein can prevent DCS and also treat it subsequent to provocative diving. Human studies investigating the potential for human recombinant pGSN to prevent inflammatory responses to provocative diving are underway and this presentation will summarize the scientific basis and progress on this investigation.
ABSTRACT
El Guavio Hydroelectric Plant (1,260 MW), operated by Enel Colombia, faces an accelerated sedimentation process threatening the operability of its deep water intake, located approximately 135 m below the reservoir's mean level. Given the impossibility of constructing a new permanent intake in the short term, SKAVA Deep Solutions designed, fabricated and installed an innovative temporary solution: a perimetral protection screen composed of 24 prefabricated steel sheet-pile modules, installed entirely through saturation diving at great depth, in zero-visibility conditions and with ROV assistance.
The intervention increased the effective operational height of the intake structure by 7.8 m, extending the service life of the intake by approximately four additional years. The project was completed within the scheduled plant shutdown, with no disabling incidents and no environmental impact, establishing a milestone in high-altitude underwater engineering in Latin America.
Keywords: deep water intake, sedimentation, sheet piles, saturation diving, temporary rehabilitation, Guavio.
1. INTRODUCTION
Deep water intakes in hydroelectric plants constitute strategically critical infrastructure whose operation may be compromised by sedimentation processes that exceed original design projections. In the context of increasing climate variability, rates of solid material accumulation in high-altitude reservoirs tend to accelerate, prematurely reducing the service life of intake systems and increasing the risk of particulate matter entering the turbine train.
El Guavio Hydroelectric Plant, one of Colombia’s most powerful facilities with 1,260 MW of installed capacity, faces precisely this scenario. Its original intake was designed to withstand approximately 35 years of sediment accumulation; however, adverse climatic factors caused sedimentation rates significantly higher than projected, reducing the structure’s operational horizon.
Given the impossibility of constructing a permanent intake in an alternative location in the short term, an interim plan was activated with the objective of extending the operation of the existing intake for approximately four additional years. This paper describes the underwater engineering solution developed by SKAVA Deep Solutions, a company specializing in deep-water operations, which led the design, fabrication and installation of a perimetral protection screen under extreme conditions.
2. CONTEXT AND PROBLEM STATEMENT
2.1 Infrastructure Description
The deep water intake of Guavio Plant operates at approximately 135 m below the reservoir’s mean water level. The structure consists of concrete edges supporting a metallic grating cage that allows water flow to enter the pressurized conveyance system.
The original design provided for a service life of approximately 35 years against progressive sediment accumulation. The hydrostatic pressure at this depth exceeds 13.5 kg/cm², imposing severe constraints on both materials and intervention procedures.
2.2 Sediment Accumulation: The Critical Threat
The primary operational risk in high-altitude reservoirs lies in the progressive increase of sediment levels. Due to natural hydrodynamic processes and upstream erosion, the reservoir floor experiences a constant accumulation of solid material (sands, gravels and silts). This accumulation posed a critical threat of reaching the elevation of the intake tower’s suction screen, with potentially catastrophic consequences:
● Erosive damage to turbine blades: the abrasive material would act as an accelerated wear agent, drastically reducing equipment efficiency and service life.
● Obstruction of auxiliary systems: clogging of cooling ducts and control circuits.
● Instability of the national power supply: unscheduled shutdowns for emergency repairs would compromise the stability of the interconnected grid, with large-scale economic and social impact.
3. GENERAL CONCEPT
The objective of the interim plan was to allow additional sediment accumulation against the intake walls without allowing it to enter the turbine flow. To achieve this, the approach proposed blocking water passage through the vertical faces of the intake cage, allowing flow only through the top face.
In this way, the effective permissible sedimentation height was increased, temporarily extending operations while a permanent solution was developed elsewhere in the facility. The heightening structure had to be structurally robust against the hydrodynamic suction forces generated during full-load operation, and its installation had to be feasible at 130 m depth under near-zero visibility conditions.
4. OPTIMIZED DESIGN DEVELOPMENT
4.1 Propuesta Inicial del Client
Enel provided a basic engineering-level solution based on steel plates bolted directly to the existing screen. This alternative presented critical limitations that compromised both its constructability and its effectiveness:
● No sealing solution between the plates and the concrete.
● Incomplete sizing of fastening bolts.
● Undefined overlaps at structural corners.
● Lack of guaranteed watertightness.
● High degree of direct human intervention, not feasible at 130 m depth under zero-visibility conditions.
4.2 SKAVA's Proposed Solution: Sheet-Pile Modules
SKAVA’s first task was to review the constructability of the basic design and propose an alternative that would guarantee watertightness and ease of installation, reducing human exposure to the absolute minimum.
After evaluating multiple alternatives, a solution based on prefabricated high-strength steel sheet-pile modules was adopted. A total of 24 modules were designed, manufactured entirely in steel and protected with anti-corrosion coating systems certified for long-term submerged environments.
The interlocking system inherent to the sheet piles enabled sequential module engagement, achieving a complete seal around the intake perimeter. The core elements of the optimized design were:
● Prefabricated and stiffened modules: welded with stiffening beams, fully assembled and dimensionally validated in the workshop prior to transport.
● Specialized bottom seal: each module incorporated a perimetral bottom seal to ensure waterproofing at the interface with the concrete structure.
● Bolted shear connections: designed to ensure structural load transfer between adjacent modules and resist suction forces during full-load operation.
● Blind-assembly design: male-female interfaces and high-security bolts enabling precise fit without direct visual contact.
For model validation, advanced computational fluid dynamics analyses were conducted to ensure the structure could withstand not only static hydrostatic pressure exceeding 13 kg/cm², but also the dynamic suction forces generated when the plant operates at full load (1,260 MW).
5. DEPLOYMENT LOGISTICS
The mobilization of resources for this project entailed a continental-scale logistics operation. The saturation diving system was transported from Mexico in a multimodal operation (maritime and overland) under strict international industrial safety standards.
Once in Colombian territory, more than 1,000 metric tons of equipment crossed the complex Andean road network. A fleet of 89 trucks transported everything from heavy steel structures to delicate hyperbaric life-support systems. Breathing gas management represented another major challenge: at 130 m depth, atmospheric air becomes toxic, requiring the preparation and transport of 4,500 m³ of helium and 1,000 m³ of oxygen for the formulation of the Heliox mixture used in saturation operations.
Construction operations were organized into three simultaneous work fronts:
● External logistics front: support operations in Bogotá, Cartagena de Indias, the reservoir shoreline, and other staging and coordination points.
● Main floating platform: a modular structure of 18 interconnected flexiboats, covering approximately 700 m², anchored at four points directly above the intake. It housed the 100-ton main crane, the ROV control station, and the saturation module "El Dorado".
● Direct underwater front: execution of works at the intake using saturation divers at 130 m depth.
6. OPERATIONAL EXECUTION: INSTALLATION UNDER EXTREME CONDITIONS
6.1 Saturation Diving
The most critical activity of the project was carried out using saturation diving technology. This procedure allows the divers’ bodies to equilibrate with the gas pressure at the working depth, eliminating the need for daily decompressions and enabling extended periods of effective bottom work.
The divers remained under saturation throughout the approximately 30-day campaign inside the "El Dorado" module, descending via a diving bell. Each dive deployed two divers, though only one performed active work. Operations were organized in 8-hour shifts with a rotating team of six divers, ensuring uninterrupted operational continuity.
6.2 Assembly Under Zero-Visibility Conditions
At 130 meters depth and in zero-visibility conditions, a diving team successfully performed a tactical assembly working entirely by touch. Mission success depended on an advanced technological network that included:
- Continuous communication: linking the surface supervisor, the diving bell, and the diver.
- Digital visualization: high-resolution sonar systems monitoring the area in real time.
- Robotic assistance: an ROV was used to position and deliver each module with exact precision prior to final manual adjustment.
6.3 Lifting Engineering and Millimetric Positioning
The lowering of the heavy modules was carried out using high-capacity cranes integrated into the floating platform. Rigorous Lifting Plans were implemented, accounting for submarine current dynamics and the effect of pressure on component stability.
Synchronization between the surface operator and the underwater team enabled control of the "pendulum effect" of loads at depth, allowing each component to engage precisely with its structural guides. This procedure was repeated systematically until all 24 modules were installed, after which the bolted shear connections were fitted and the assembly was verified through a final ROV survey.
6.4 Safety Management and Operational Continuity
Operations were sustained continuously for more than 30 days. Logistical support was reinforced by a fleet of support vessels managing the constant flow of supplies, personnel and materials. The physical well-being of the divers was overseen by a specialized medical team and life-support technicians, who provided uninterrupted supervision of saturation chamber conditions, managing gas mixtures and decompression procedures in accordance with international standards.
The project was executed by 140 specialized professionals from Chile, Colombia, Brazil and Mexico. The technical expertise of the team, complemented by constant on-site supervision, enabled the completion of operations with zero disabling incidents and no environmental impact on the reservoir ecosystem.
7. RESULTS ACHIEVED
The implemented temporary solution delivered the following quantifiable results:
● A 7.8 m increase in the operational height of the intake structure, enabling greater sediment accumulation without entry into the turbine flow.
● Extension of the intake’s service life by approximately three additional years, providing the time margin required for the development of the permanent intake solution.
● Execution completed within the scheduled plant shutdown, confirming the constructability of the methodology under extreme conditions.
● Zero disabling accidents and zero environmental impacts recorded throughout the entire campaign.
8. LESSONS LEARNED
The execution of the temporary heightening at Guavio yielded high-value lessons for future interventions in deep hydraulic infrastructure:
● Constructability as the primary design criterion: in works at great depths and under zero-visibility conditions, success depends on engineering conceived from the earliest stages with assembly constraints, logistics and minimization of human exposure in mind.
● Modular approach to risk minimization: the prefabricated modular design significantly reduced the need for direct human intervention, requiring only one active diver per installation operation.
● ROV-diver integration as a standard methodology: the combination of remotely operated vehicles for positioning and geometric control with saturation divers for fitting and fastening maneuvers proved decisive for the precision and safety of the installation.
● Pre-installation workshop validation: the complete pre-assembly of all modules before transport to site prevented dimensional interferences during underwater installation, saving critical dive time.
● Gas management in high-altitude logistics: advance planning of Heliox mixture supply at industrial-scale volumes is essential to ensure operational continuity in projects of this magnitude.
9. CONCLUSIONS
The temporary heightening of the deep water intake at El Guavio Hydroelectric Plant constitutes a singular case in Latin American underwater engineering. SKAVA demonstrated that it is possible to design, fabricate and install highly complex structures at extreme depths, under zero-visibility conditions and to world-class safety standards.
The solution based on prefabricated sheet-pile modules, optimized for remote installation with minimal direct human intervention, overcame the limitations of the original basic design and delivered a structure with validated hydraulic, structural and watertightness performance. The effective integration of saturation diving and ROV as complementary tools made the decisive difference in the feasibility and safety of execution.
Beyond the immediate result, this project provides a replicable methodological model for the temporary rehabilitation of hydraulic infrastructure affected by accelerated sedimentation in deep-water contexts, contributing to the energy resilience of large-scale hydroelectric systems across Latin America and the world.
Kongsberg’s Listen is a passive electromagnetic sensor system designed for measuring electric and magnetic fields in seawater and optimized for integration on HUGIN AUVs. When installed on HUGIN, Listen uses hull‑flush‑mounted electrodes arranged into eight electrode pairs to reconstruct the full three‑dimensional electric field, combined with magnetometers that provide complementary magnetic measurements. This configuration enables low‑noise, repeatable data acquisition well suited to long‑range AUV missions.
Listen supports contactless cathodic protection (CP) inspection by exploiting the electric fields generated by active CP systems. A HUGIN AUV equipped with Listen can survey pipelines at typical altitudes of 5–10 m and speeds of 3–4 knots, continuously measuring the 3D electric field without physical contact. From these measurements, anode output currents, return currents into the structure, and anode material consumption rates can be estimated, enabling assessment of CP performance, coating condition, and remaining lifetime. The electromagnetic data can be integrated with navigation, camera, and multibeam echosounder data to deliver decision‑ready integrity information with high productivity and reduced operational risk.
Beyond CP inspection, Listen enables buried power cable detection, positioning, and burial‑depth estimation. Sea trials with the Listen receiver system deployed on a Hugin Superior AUV demonstrated high signal‑to‑noise electric and magnetic field measurements at the 50 Hz powerline frequency across multiple passes and altitudes. The results showed reliable cable detection at altitudes up to 20 m and burial‑depth estimation using combined electric‑ and magnetic‑field analysis, highlighting the value of multi‑field sensing compared to magnetic‑only approaches.
Ensuring the long-term integrity of subsea pipelines and seafloor assets is one of the most critical challenges in offshore energy operations. Traditional cathodic protection (CP) surveys often rely on intrusive methods or limited data acquisition, resulting in partial insights into corrosion risk and system performance. Ocean Floor Geophysics’ (OFG) patented integrated Cathodic Protection (iCP) technology represents a step-change in subsea asset integrity management—delivering non-intrusive, high-resolution, and spatially continuous assessments of cathodically protected systems.
The iCP system employs an innovative EMF sensing approach to detect and map the electrical and magnetic fields associated with CP currents, without requiring physical contact with the asset. This capability enables accurate characterization of CP performance of pipelines and subsea assets. By eliminating the need for direct electrical contact, iCP minimizes operational risk, reduces survey time, and allows for assessments over extensive pipeline sections and complex infrastructure.
OFG’s iCP technology can be deployed via Autonomous Underwater Vehicles (AUVs) or Remotely Operated Vehicles (ROVs), offering flexible and scalable inspection strategies. During deployment, the system collects synchronized, high-density electromagnetic data, which are processed to generate detailed maps of current distribution and potential gradients. The result is a comprehensive and quantitative view of CP system health—providing engineers with the actionable intelligence required to evaluate system adequacy, detect anomalies, and plan proactive maintenance interventions.
The insights derived from iCP measurements extend beyond basic compliance verification. By integrating these data into advanced modeling workflows, asset integrity teams can predict coating degradation, estimate remaining CP life, and design optimized retrofit or life-extension programs based on measured, rather than assumed, performance. The technology thus bridges the gap between inspection data and engineering decision-making—supporting more sustainable, data-driven management of subsea assets throughout their operational lifecycle.
In this presentation, Ocean Floor Geophysics will showcase field results from recent iCP deployments on active subsea pipelines and production assets, illustrating the system’s ability to deliver unparalleled resolution and interpretive power. The discussion will highlight how non-intrusive CP monitoring transforms both the understanding and visualization of cathodic protection systems, setting a new benchmark for integrity assessment in the offshore sector.
Deeper dive into HSE key perfomance indicators. Discussion beyond common leading and lagging indicators. How many exposure man hours between high potenital events. Cost of HSE per exposure man hour. HSE competncy assessmnts. Leadership competency assesments.
The complex circulation of the Gulf of America, driven by the Loop Current (LC), Loop Current Eddies (LCEs), and cyclonic eddies (CEs), poses significant risks to offshore operations. Accurate identification of the location and intensity of these features is critical for defining safe operational windows but requires integration of diverse observational datasets.
This paper presents a frontal detection methodology in which the boundaries of LC/LCE features are estimated by the position of the 1.5‑knot isotach. The resulting fronts are used to characterize feature location and current intensity and validate numerical model output. The approach has been evaluated extensively since 1984 and is widely regarded as representative of ground truth for the placement of major oceanographic features in the region.
This session will provide and overview of what is legally required of commercial diving contractors and their divers.
The 2023 Titan accident exposed significant gaps and inconsistencies in the international oversight of submersibles, placing lives at risk and undermining public confidence in the industry. In response, the MTS Submarine Committee and the World Submarine Organization (WSO) are working toward a more effective international governance framework for identifying submersibles and overseeing their operation, with the long-term objective of harmonization through the International Maritime Organization (IMO).
This presentation will provide an overview of the current state of the civilian submarine industry and examine the findings and recommendations arising from investigations by the U.S. Coast Guard, the U.S. National Transportation Safety Board, and the Transportation Safety Board of Canada. It will also report on the WSO Annual Flag State Meeting, held in Hamburg on September 15–16, 2026, where maritime and port authorities from approximately 15 countries will discuss a practical framework for improving submersible identification and regulatory oversight while balancing differing national requirements with the need for international consistency.
This presentation covers Commercial Diving and Mental Health as it relates to:
It does not cover Cliynical Phycology definitions of Mental Health.
It is currently a 40-45 min presentation. It could be trimmed if needed.
I will be attending the IOGP DOSC and IDIF all day meetings so if chosen it would need to be scheduled for the off day which I think will be Friday the 4th.
The underwater exploration company OceanGate publicly changed its procedures to reject established engineering codes and standards. They publicized they were going to innovate “like NASA” by developing a novel carbon fiber composite hull for its third submersible, the TITAN. The TITAN’s loss at sea with five people aboard in June 2023 captured worldwide media attention, which subsequently impacted the resulting investigations. This was the first loss of a non-military submersible in over 50 years and the first to be subject to a Marine Board of Investigation. The joint US Coast Guard/National Transportation Safety Board investigation brought much of the investigation process into the public, including the public hearings in 2024 and the publishing of the separate reports and findings of the USCG and NTSB in 2025. Kemper Engineering Services was the only non-governmental organization that was part of the official investigation. This presentation will be a summary of our findings, including the detailed failure analysis that indicates a second hull delamination between a 1-inch cured section is the most likely root cause of the implosion. We will also present our finding regarding design methods, simulation methods, acrylic window design, and air supply.
No sessions match your current filters.
Despite technological development addressed to ocean-monitoring has been significantly improved during the last two decades with new platforms, sensors and telemetry systems, there are still many unsolved gaps in terms of data quality, reliability, efficiency and sustainability. Ocean glider technology (including autonomous underwater and surface vehicles) offers a new approach in terms of monitoring capacity and sustainability, enabling to perform observations in spatiotemporal scales hitherto unavailable.
PLOCAN Glider School is a hands-on ocean-glider technology and training forum mainly addressed to ocean-glider technologies and their wide range of monitoring applications learning. Students and professionals from marine and maritime fields interested in learning about this specific and emerging autonomous ocean vehicle technology are truly welcome to join in. The PLOCAN Glider School is a training action promoted by PLOCAN in line with international programs and projects such OceanGliders, EuroGOOS, AQUARIUS, among others, that provides a state-of-the-art overview and the operational basis approach to this technology through theoretical and practical teaching sessions in both wet-lab and open waters of Gran Canaria.
Leading corporate partners and key-reference research institutions across Europe and USA closely cooperate with the PLOCAN Glider School by teaching some of the didactical program contents, that includes as main topics (for each glider technology) a technology overview, nuts and bolts: how it works, mission setup and piloting, deployment and recovery in open waters, data management and applications, maintenance, etc.
The present work attempts to summarize the role and contribution summary of fifteen years of PLOCAN Glider School where more than two hundred-fifty attendees from thirty-six countries of the five continents have been trained, in addition to the support by twenty-eight leading companies (as technology developers in this field) and institutions (as leading operators and end-users), enabling new user groups and the international glider-community growth in support to initiatives such EOOS and GOOS aiming to a more efficient and sustainable global ocean-observing strategy based on this cutting-edge technology.
IMCA Diving 202-2027: What we've done and what we're going to do
Every operator in the offshore inspection space is managing the same set of constraints. Vessel day rates run $50,000 to $100,000. Mobilization takes weeks. The crew shortage is structural: BIMCO forecasts a 90,000-officer shortfall, DP certification takes two years per operator, and the ROV workforce is staffed to about 73% of demand. A $65 billion construction backlog is creating decades of new inspection obligations on top of existing requirements. Routine inspection that should happen on a regular cadence gets deferred, bundled, or skipped because the cost to mobilize is out of proportion to the scope.
This presentation argues that both the technology and the business model for offshore inspection are changing, and that the change matters for anyone who operates, manages, or contracts workboats for survey and inspection work.
Standard Subsea is building and operating these systems today. Scout is a 14-foot, all-electric uncrewed catamaran carrying hull-mounted sonar, USBL tracking, and an inspection-class ROV rated to 300 meters. It launches from a boat ramp on a standard trailer. Two operators pilot both vehicles from shore over Starlink. The system costs $500,000 to build fully loaded. The key technical development is a custom between-hull launch and recovery system that cycles an inspection-class ROV from an unmanned platform, closing the loop on complete inspection from shore with nobody on the water.
But building a cheaper vehicle does not change an industry if the procurement model stays the same. Today, every inspection job follows a rigid sequence: identify a need, scope a project, solicit bids, award a contract, wait weeks for mobilization, execute the campaign, demobilize, wait for the report. That process exists because the assets are expensive and scarce, so every engagement has to justify itself as a standalone project. Standard Subsea is replacing that entire workflow. Credit-based pricing where a day of inspection, vessel, ROV, operator, data processing, and deliverables, is a published line item. No RFPs. No six-figure scoping exercises. Same-week turnaround. An inspection campaign becomes a series of service calls that customers budget as a recurring operational expense.
When you remove the procurement friction alongside the mobilization cost, the calculus around inspection changes. Pipeline operators running GVI and CVI on aging infrastructure get faster inspection cycles and earlier visibility into integrity issues. Port authorities survey seabed and structures without shutting down berths for a crewed vessel. Decommissioning campaigns get pre-decom baselines, monitoring during removal, and post-decom clearance from one asset instead of scheduling separate charters for each phase. Mooring inspections that get deferred because a two-day job cannot justify a full mobilization actually get done. The same annual budget that bought one inspection campaign from a crewed vessel buys five.
The long-term vision is not a tool. It is an operating system. Regional hubs permanently positioned near concentrations of offshore infrastructure, where operators book inspection the way they book any recurring service. Over time, compliance calendars get built around hub availability. Maintenance budgets get structured around published pricing. Annual inspection plans assume same-week turnaround instead of six-week mobilization windows. Every mission generates operational data that compounds into predictive maintenance baselines and digital twin datasets, which means inspection shifts from verifying what went wrong to anticipating what will. The customer's entire planning apparatus reorganizes around the hub, and once that happens, the value is no longer in any single vehicle. It is in the fact that everything around it has been redesigned to assume it is there.
That model does not replace crewed vessels across all offshore work. It replaces them for routine, repeatable inspection, freeing crewed assets and qualified crew for the complex jobs that actually require them.
By December 2026, Standard Subsea will have completed five commercial programs across three continents: cable pre-survey off California, port infrastructure survey in the Great Lakes, pipeline and jacket inspection in the Gulf of Suez, cable route survey in the South Pacific, and a public sector coastal security survey in U.S. waters. This presentation draws on those programs to cover the technology, the business model, the per-day economics, and where this class of system reaches its limits.
The rapid growth of offshore renewable energy, subsea infrastructure, autonomous systems, and ocean technology is creating significant demand for a highly skilled underwater workforce. At the same time, employers face persistent shortages of qualified technicians, engineers, ROV operators, and marine professionals with the competencies needed to support increasingly complex operations. Addressing this challenge requires innovative workforce development models that connect education, industry, and government.
This presentation highlights the Fisheries and Marine Institute of Memorial University of Newfoundland as a case study in building a responsive workforce ecosystem for the blue economy. Through industry-informed academic programs, applied research, customized training, and work-integrated learning, the Marine Institute prepares graduates and professionals for careers in underwater operations, marine engineering, ocean mapping, autonomous systems, and offshore industries.
The presentation examines how competency-based education, stackable credentials, experiential learning, and strong industry partnerships ensure that training remains aligned with evolving workforce needs. It will also explore strategies to increase participation by engaging veterans, women, Indigenous learners, career changers, and students from coastal communities, creating more inclusive pathways into marine careers.
Participants will gain practical insights into developing sustainable education-to-employment pipelines that support workforce readiness, innovation, and economic growth. By demonstrating how collaboration among academia, industry, and government can address critical skills shortages, this session provides a model for preparing the next generation of professionals to support safe, resilient, and technology-driven underwater operations throughout the global blue economy.
Orpheus Ocean builds and operates ultra-scalable autonomous underwater vehicles for deep ocean and seabed data collection. In this talk we begin with an overview of the capabilities and novel design philosophy behind the Orpheus AUV, which enables high resolution benthic survey, sample retrieval, and long duration monitoring, in a single agile platform. The Orpheus AUV is intended primarily to automate and scale seafloor work typically performed by ROVs, and can be deployed from small vessels of opportunity. We review results from recent deployments, including deep exploration with NOAA at >5,000m, and exercises with the DoW. Data, results, and learnings from deployment of the prototype vehicles will be shared. Finally, we discuss the potential applications of the Orpheus approach to various mature and emerging industries including seabed minerals, subsea infrastructure, and defense.
Twenty-four nautical miles off San Francisco, California, Open Ocean Robotics, as part of Team @Orchard, is maintaining continuous observations at NOAA National Data Buoy Center Station 46012 without a moored buoy or permanent shoreside infrastructure. Since January 2026, the service has combined rotating solar-powered uncrewed surface vehicles (USVs), remote fleet operations, and local support for launch, recovery and shoreside servicing.
The DataXplorer USVs use controlled station-keeping to collect wind, atmospheric and surface-ocean measurements. Hourly datasets are transmitted through redundant cellular and satellite communications for NOAA quality-control and dissemination workflows.
Continuity is achieved by rotating USVs between the offshore station and shore. While one vehicle remains on station under Open Ocean Robotics’ control, another can be recovered, inspected, serviced and recharged by the local operator. This model reduces reliance on specialized vessels, permanent field crews, and travel by technical personnel.
A field-deployed solar charging trailer provides independent shoreside power, battery storage and connectivity at a location without conventional marine or electrical infrastructure. This capability supports year-round service during periods when onboard solar generation cannot sustain continuous operation by a single vehicle.
The presentation will share practical lessons in fleet rotation, remote vehicle and sensor monitoring, local-operator coordination, energy management, launch and recovery, preventative maintenance, and continuity of data delivery.
This operating model reframes persistence: the measure is not how long one vehicle remains at sea, but how reliably the overall system delivers uninterrupted observations. The approach could also support persistent surface gateways for seabed instruments, underwater vehicles, and acoustic sensor networks in remote coastal, offshore and northern environments where permanent infrastructure and frequent specialist-vessel visits are impractical.
Lessons from other energy sectors show that workforce constraints can slow deployment and delay commercialization, even when the technology is ready. Without a skilled workforce in place, progress stalls.
The marine energy sector is no different; its growth depends on a workforce prepared for both engineering and offshore operations. The question is: Are we preparing the marine energy workforce fast enough to meet projected industry demand?
To better understand workforce readiness and identify critical gaps, the National Laboratory of the Rockies (NLR), with support from the U.S. Department of Energy’s Hydropower and Hydrokinetic Office (H2O), conducted a marine energy workforce assessment in 2024.
Building off a 2019 baseline assessment, this study integrates data from educational institutions and industry stakeholders to provide a comprehensive, system-level analysis. NLR applied a mixed-methods approach to characterize the availability of marine energy curricula, trainings, and field-based learning, and assess industry workforce preparedness. This included:
Key findings from the education assessment
Findings show that dedicated marine energy programs remain limited. Among the surveyed institutions, only one reported an associate degree, three reported undergraduate degrees, and two reported graduate-level programs explicitly focused on marine energy. More commonly, marine energy content was embedded within mechanical engineering, ocean engineering, or environmental science curricula.
While 56% of responding schools incorporated some coverage of marine energy topics, sustained programming was constrained by inconsistent funding streams, limited dedicated faculty, and low course enrollment. Institutions with access to field deployments, specialized facilities, or competitions (e.g., the Marine Energy Collegiate Competition) reported higher levels of student engagement and retention.
Key findings from the industry assessment
Industry perspectives reinforce the need for workers in the near future (58% of respondents plan to increase staff in the next 5-10 years) and interdisciplinary skillsets, combining core engineering competencies and maritime operational experience with commercialization and business acumen. Employers report persistent challenges in recruiting candidates who combine technical expertise with practical, field-based or offshore experience in safety-critical environments.
These workforce gaps mirror challenges seen in subsea operations, offshore construction, and marine robotics, where field experience and safety-critical skills are essential.
In response, with H2O's support, NLR is implementing workforce development strategies to strengthen the workforce pipeline, including experiential learning models (student competitions), career pathway tools (e.g. the Marine Energy Career Map), and pilot fellowship programs.
These findings highlight a need for training models that better integrate classroom learning with hands-on, field-based experience, as well as opportunities to transition skilled workers from adjacent maritime, offshore, and subsea industries into marine energy roles.
What to expect
This presentation will:
In addition, NLR has conducted longitudinal student surveys since 2020 s to track how student perceptions of marine energy viability and careers have changed over time.
This session will provide attendees with actionable insights into workforce gaps, training needs, and strategies that can support deployment and reduce workforce-related bottlenecks across marine and offshore industries. By sharing research findings with UI attendees, NLR aims to exchange best practices and bring together the stakeholders across the offshore community to discuss shared challenges and needs.
An in-depth review of the current U.S. Subsea Vessel Fleet, the impact of recent consolidation developments between vessel owners and contractors, a shift in focus towards more DSVs, and some comparables with other regions worldwide.
The recent consolidation between Hornbeck and Helix, Saipem and Subsea 7, the acquisition of Harvey Gulf Subsea fleet by Otto Candies, and a raft of M & A activity by Chouest, has significantly shaken up the U.S. subsea vessel landscape. What impact will such consolidation have on the market in the short and long-term for Charterers and end clients? What comparables can we draw with the North Sea and other regions? What are some of the barriers to newbuild vessels in the offshore market and how can these be overcome? What impact has the rise and fall of the offshore wind market had on the U.S. subsea fleet?
The Saturation Diving Market in the U.S. has been dominated by a very small number of players and vessels yet it has seen a recent increase in activity from new entrants and converted vessels for this market - is the market ready for more players and what is driving this renewed interest?
As the blue economy expands across offshore energy, coastal engineering, emergency preparedness, and maritime technology, employers face a growing workforce gap. The Advanced Research & Innovation Institute (ARII) has developed a 9-month workforce model designed for young adults ages 18–24 that combines six months of hands-on academic training with a three-month paid internship placement with industry partners.
This session will explore the development of ARII’s Coastal Academy, including curriculum design, industry alignment, small-cohort training, and measurable workforce outcomes. Attendees will gain insight into building regional workforce pipelines, securing industry partnerships, and aligning training programs with emerging coastal and offshore technologies.
The session will also highlight lessons learned from designing and deploying Massachusetts’ first nearshore sensor network and how applied research can directly support workforce development.
Underwater robotics, aquaculture monitoring, and subsea inspection are increasingly driven by AI and machine vision, but most systems still rely on imaging hardware that was never designed for operation in water. We’ll walk through a comparative optical study showing how common subsea camera architectures perform — from flat and dome ports to corrector optics — and contrast those with purpose-built wet lens designs. The takeaway is not just better images are possible, but more reliable perception, lower downstream compute requirements, and better real-world AI performance are possible even in challenging underwater environments.
Underwater imaging often relies on adapting terrestrial camera lenses for subsea use through flat or domed optical ports. While convenient and cost-effective, these configurations introduce optical compromises due to refractive index mismatches at the air-glass-water interface and lens designs optimized for in-air use. This talk presents a comparative performance analysis of several underwater port configurations, including flat ports, hemispherical domes, Ivanoff-Rebikoff correctors, and a multi-element custom "wet" port, alongside a fully customized underwater lens system explicitly designed for direct operation in seawater.
Optical metrics, including modulation transfer function (MTF), lateral chromatic aberration, field of view (FOV), and image simulation fidelity, are evaluated. Results show that terrestrial lenses with port adaptors suffer significant degradation in image quality, while Ivanoff-Rebikoff correctors recover resolution but leave residual chromatic and geometric distortions. The Optopax custom port further improves performance, while the fully customized underwater lens surpasses all configurations, delivering superior MTF, complete chromatic correction, and field preservation, along with form factor flexibility for integration into space-constrained platforms.
Simulated Siemens star charts and real-world scenes demonstrate significantly enhanced edge definition, spatial detail, and color accuracy with both the custom port and the bespoke wet lens. By eliminating the optical discontinuities at air-glass interfaces and leveraging seawater as an active optical medium, the fully customized design represents a new design strategy in subsea optics, enabling high-fidelity imaging for underwater robotics, aquaculture monitoring, and AI-enhanced marine vision applications.
A revolution in offshore survey and inspection is accelerating. Autonomous systems, long-promised to replace crewed survey vessels, and their cost, are reaching a level of maturity where this reality is now within sight.
However, challenges remain to fully decouple from crewed vessels. Today, most AUVs still need to be launched and recovered from a crewed vessel. These exquisite systems command a high day-rate and haven't repeatably proven that they reduce enough ship days-at-sea to justify the cost.
Ulysses is working to address these challenges in two ways: by building the lowest-cost platforms in their class and the ability to autonomously launch-and-recover multiple systems from a single uncrewed vessel. Through this approach, Ulysses will achieve a step-change, unlocking a truly cost-effective approach to persistent data collection and monitoring of subsea assets.
Learn how a high school ROV team from rural Michigan conducted an ROV workshop in the Dominican Republic.
The Stockbridge Jr/Sr High School ROV was invited to conduct research, test equipment and conduct an educational outreach project in the Dominican Republic, February 23 to March 1, 2026.
The procets aimed to Inspire, Engage, and Educate students while providing a unique research experience in the Caribbean Islands. The project had three main goals; (1) to connect with a school in the Dominican Republic to share knowledge and culture between students, and conduct a STEM program. (2) to conduct an ROV Workshop for a STEM class at the Punta Cana International School. (3) to donduct ocean and reef monitoring off the coast of the Dominican Republic.
Operators in the renewable energy and oil and gas industries rely upon Controlled Flow Excavation (CFE) technology to support complex scopes – with the triad of ever-greater performance, efficiency and environmental impact driving continual development.
With more than 640 successful CFE projects to our name worldwide, James Fisher has over 25 years of practical experience in safe, efficient, non-contact seabed intervention. James Fisher introduces JetFlow 100 as the next generation of CFE technology, designed to overcome increasingly challenging soil conditions while maintaining efficiency and cost-effectiveness.
JetFlow 100 is versatile, with a compact footprint and high excavation performance enabling a variety of inspection, maintenance, repair, and commissioning and decommissioning activities across the oil and gas and renewable energy industries. Uses include both pre- and post-installation trenching of pipelines, umbilicals, and subsea infrastructure, or seabed deburial to support structure inspection or decommissioning activities.
JetFlow 100 is a step change in subsea excavation capability. By significantly increasing flow power and jetting efficiency, the system enables effective excavation in stiffer soils and clays—conditions where conventional CFE tools have historically struggled. This optimal balance between mass flow rate and velocity is achieved without needing to add large, high-pressure jetting spreads, thereby reducing vessel deck space requirements and contributing to lower overall project costs.
James Fisher has combined the key advantages of non-contact excavation with the capability to operate across a wide range of soil strengths – including clays up to ~100 kPa - in standard configuration.
This ensures minimal risk to subsea assets while delivering consistent, repeatable trenching performance, and expands the applicability of CFE methods into projects that would traditionally require more complex, resource-intensive solutions.
The system has undergone successful testing in Aberdeen, UK, demonstrating stability and performance across a range of operating conditions without compromising tool integrity. These results validate the design philosophy of enhancing excavation power while maintaining operational simplicity and reliability, with JetFlow 100 now available to customers throughout the Americas.
This paper will present the development journey of JetFlow 100, including design innovations, testing and simulation results, and its potential to re-establish CFE as a preferred methodology in subsea project planning. The discussion will also explore how this technology can unlock efficiencies in future offshore operations by reducing cost, complexity, and environmental impact, both in North American waters and beyond.
James Fisher is running an advanced simulation programme to de-risk and optimise the design of our CFE tools such as the JetFlow 100, and to demonstrate their effectiveness. We are investing in sophisticated simulation tools and developing cutting-edge simulation techniques to perform simulations and ensure simulation results are representative of real life.
With rigorous simulations and testing underway throughout the year, additional data will be shared at Underwater Intervention in December 2026.
Autonomous subsea vehicles are evolving beyond discrete mission tools into integrated operational systems. Among the most promising developments is the emergence of port‑launched, long‑range unmanned underwater vehicles (LUUVs) designed to deliver persistent, lower‑logistics subsea survey and infrastructure awareness without reliance on vessel‑intensive operations.
This presentation explores how advances in vehicle architecture, endurance, navigation, and onboard edge processing are enabling a new operational model for autonomous survey. By exploiting data at the point of collection and integrating persistent data workflows, these systems reduce time to insight while expanding coverage and operational flexibility.
Topics include the design considerations of long‑range autonomous platforms, navigation and sensing strategies, onboard data exploitation, and how repeatable autonomous missions create compounding value through continuous infrastructure awareness. The session will also examine representative operational concepts—ranging from completed activities to near‑term deployments—to illustrate how port‑launched autonomy can support scalable survey operations across offshore and coastal domains.
Ultimately, the presentation positions autonomous UUVs not as standalone vehicles, but as system‑level enablers—reducing logistics, increasing persistence, and making subsea survey and monitoring more economically and operationally practical for a broader range of users.
The MATE Floats Marine Technology Summer Workshop is an advanced, immersive, multi-day learning experience around float technology, sensors, programming, and data science. Hosted by the University of Washington's (UW) School of Oceanography, the goal of this five-day workshop is to provide students with 1) the opportunity to learn about and experience marine technologies first-hand and 2) to develop and build upon the skills they will need for success in the technical workplace.
The target audience is two-year community and technical colleges students from across the U.S. Community and technical colleges serve diverse populations; students at these institutions are less likely to have access to these opportunities, which makes programs like MATE Floats critical to increasing and diversifying the potential talent pool prepared to enter the marine technical workforce.
This presentation will include an overview of the workshop. Student participants will also present information about their workshop experience, including a shipboard experience on the UW's R/V Rachel Carson, skills gained, and the data science project completed during the workshop.
MATE Floats is funded by two National Science Foundation-funded projects; the National Center of Autonomous Technologies and the Global Ocean Biogeochemistry (float) Array (the Monterey Bay Aquarium Research Institute is the lead on the GO-BGC project). MATE Floats is one of several summer workshop opportunities presented by the Marine Technology Society.
The highest-risk portion of subsea cable infrastructure receives the least attention. The coastal band within the first 200 feet of water accounts for roughly 15–20% of total installed mileage but a disproportionate share of recorded failures. Large DP2 vessels are too costly to deploy in these depths, while small coastal craft lack the endurance and sensor payload for high-quality inspection. This gap leaves a critical portion of the global network effectively invisible and forces operators into reactive maintenance rather than proactive monitoring.
This presentation introduces a new approach to shallow-water survey using remotely operated surface vessels. Scout-18, an 18-foot unmanned platform paired with a tethered ROV, replicates the core functions of an 80-meter survey ship at a fraction of the cost. The system captures video and sonar data that feeds into a software platform converting raw survey logs into continuously updated digital twins, with automated anomaly detection and integration into existing GIS and ERP systems.
We will share early findings from engagements with cable owners off the coast of California, pipeline monitoring in Egypt, and cable routing work in Vanuatu. These case studies illustrate how collapsing the unit economics of inspection enables asset owners to shift from reactive fault response to continuous situational awareness.
Attendees will gain insight into the operational and technical considerations of deploying compact unmanned survey systems in shallow water, the data workflows required to translate raw survey output into actionable intelligence, and the implications for cable protection strategies in high-risk coastal zones.
SeaTrac and the University of Southern Mississippi are working together to demonstrate the use of SeaTrac’s SP-48 uncrewed surface vessel as a persistent surface expression for uncrewed underwater vehicles, subsea sensors, and other underwater assets. The demonstration will evaluate how a low-logistics, long-endurance USV can support subsea operations by providing remote positioning, command-and-control support, and communications relay capabilities using an integrated Sonardyne Gyro USBL 5000 system.
Subsea operations increasingly depend on distributed underwater systems, including UUVs, seabed instruments, acoustic modems, and other autonomous or remotely monitored assets. These systems often require a surface node to provide acoustic positioning, data relay, mission coordination, and operator awareness. Traditionally, this role has been filled by crewed vessels, which can introduce significant cost, scheduling, endurance, and personnel-risk constraints. The SP-48 demonstration is intended to show how an uncrewed maritime system can assume many of these surface-support functions while reducing operational burden and enabling more persistent subsea presence.
The SP-48 is a 4.8-meter, solar-powered USV designed for persistent operations from nearshore environments to open ocean. It supports 24/7 operations, redundant communications, man-in/on-the-loop remote supervision, waypoint-based mission execution, AIS, 360-degree situational-awareness cameras, and multiple payload configurations. SeaTrac has previously operated the SP-48 on long-duration missions exceeding two months and 1,600 nautical miles, and has demonstrated acoustic payload operations, including a Gulf of Mexico data-harvest mission using a Sonardyne HPT 7000 payload to collect data from nine seafloor sensors over approximately 570 nautical miles.
For the proposed demonstration, the SP-48 will be configured to act as a mobile and persistent surface node for underwater assets. The system concept includes the Sonardyne Gyro USBL 5000 for acoustic tracking and positioning; onboard communications links to move vehicle, payload, and mission data ashore; and remote supervision from SeaTrac’s operations architecture. The University of Southern Mississippi team will lead test planning, evaluation, and demonstration activities, with SeaTrac supporting platform integration, operations, and mission execution. The work will assess how the integrated system performs as a surface expression for UUVs and other underwater assets, including its ability to support acoustic positioning, relay operational data, maintain mission awareness, and coordinate with shore-based operators.
This presentation will provide an overview of the demonstration objectives, system architecture, planned test approach, and results available at the time of Underwater Intervention 2026. It will discuss the operational value of using uncrewed surface vessels to support subsea work, including reduced dependence on crewed vessels, increased endurance, lower logistics, persistent access to remote operating areas, and the ability to scale support for distributed underwater systems. The presentation will also address practical considerations such as payload integration, remote operations, communications paths, safety and recovery planning, and coordination between USV operators and subsea mission teams.
The broader intent of this effort is to demonstrate that uncrewed maritime systems such as the SP-48 can provide a reliable, cost-effective, and scalable surface-support layer for subsea operations. By combining persistent USV operations with proven acoustic positioning and communications technologies, the demonstration will show a pathway toward more efficient support of UUV missions, subsea infrastructure monitoring, seafloor sensor networks, environmental data collection, and future offshore intervention activities.
The blue economy depends on a steady pipeline of skilled and connected ocean professionals, yet many students and early-career ocean professionals (ECOPs) struggle to break into the field (and stay in it) without structured support. The Marine Technology Society's (MTS) EMERGE program was built to close that gap.
EMERGE is a yearlong professional development and mentorship program pairing students and ECOPs with experienced industry mentors, providing monthly Career Accelerator Webinars, and culminating in fully supported, guided attendance at Underwater Intervention.
This presentation will share what MTS has learned across multiple EMERGE cohorts: which program elements most effectively build career confidence and professional networks, how mentorship accelerates participants' ability to navigate the industry, and what outcomes participants report in terms of career readiness, community connection, and long-term engagement with marine technology.
Layered Media Detection (LMD) represents a significant advancement in hydrographic surveying by extending the capabilities of multibeam sonar into environments where surveyors have traditionally relied on dual-frequency single beam echo sounders to assess fluid mud and layered sediment conditions. For decades, determining the extent and characteristics of fluid mud deposits has largely been a profile-based exercise, requiring surveyors to collect individual cross-sections and interpolate conditions between widely spaced survey lines. While effective for identifying sediment layers along a track line, these methods provide only a limited view of highly dynamic environments and often leave uncertainty regarding the spatial extent, thickness, and variability of sediment deposits between measurements.
Recent advances in broadband multibeam sonar processing have enabled a different approach. Layered Media Detection utilizes simultaneous multi-frequency acoustic analysis to identify and map multiple sediment interfaces during a single survey, allowing fluid mud and underlying sediment structures to be visualized as continuous three-dimensional surfaces rather than isolated profiles. This transition from line-based observations to full-coverage spatial mapping provides hydrographers, port authorities, and dredging organizations with a much more complete understanding of sediment conditions across an entire project area.
By producing co-registered datasets that reveal both upper sediment boundaries and deeper sediment structures, LMD enables the creation of detailed 3D models that illustrate sediment distribution, thickness, morphology, and change over time. Features that may be difficult or impossible to identify between single beam survey lines can be visualized directly, providing improved awareness of sediment accumulation patterns, dredging impacts, depositional trends, and other processes that influence waterway management. The ability to observe these conditions across a complete survey area rather than along discrete transects represents a fundamental shift in how layered sediment environments can be characterized and understood.
As the technology has matured through extensive field testing and operational deployments in ports, rivers, navigation channels, and dredged waterways, new applications have continued to emerge. Beyond simply extending traditional survey methods, LMD is enabling surveyors to evaluate sediment systems in ways that were previously impractical using conventional techniques. The resulting datasets support more comprehensive analysis of fluid mud behavior, sediment transport, and seabed evolution while providing a richer framework for visualization, interpretation, and decision-making.
This presentation explores the evolution of Layered Media Detection from its initial development through its refinement into an operational technology and examines how full-coverage 3D sediment characterization is changing expectations for hydrographic surveying in layered sediment environments. Through examples drawn from recent field deployments, attendees will see how advances in multibeam sonar technology are transforming what was once a sparse, profile-based workflow into a comprehensive spatial mapping capability, opening new opportunities for understanding and managing complex underwater environments.
This paper presents an overview of the latest developments in Sonardyne’s SPRINT-Nav family. Throughout 2025 and 2026 the SPRINT-Nav family has undergone a significant update, from introducing the world’s smallest hybrid navigator that was presented at Underwater Intervention last year to a complete update across the rest of the family – SPRINT-Nav M, I, S and X and beyond. Through this presentation Sonardyne will highlight how we’ve evolved SPRINT-Nav to meet the increasing demands and use cases of complete suite of marine robotic platforms.
We will demonstrate real-world case studies of SPRINT-Nav performance with a focus on their impact on survey operations. Learn how the SPRINT-Nav family is enabling small inspection ROVs and micro AUVs to navigate and position to levels that enable them to take on tasks that previously called for larger and more capable platforms. Understand how uncrewed surface vessels can reduce their reliance on potentially spoofed or jammed GNSS aiding with SPRINT-Nav taking care of vehicle navigation in a GNSS independent solution. Discover how the new generation of ultra long range extra large UUVs can transit thousands of kilometres in mid deep water without the need to surface with a reliable and precise navigation payload onboard that means mission and data are solid.
Finally, the paper will explore how collaboration with industry partners is positioning SPRINT-Nav as a critical enabler of increasingly remote and autonomous operations. Through interoperability with complementary technologies and ongoing innovation, SPRINT-Nav supports the transition toward smarter, more autonomous subsea systems, reducing operational costs while maintaining mission critical requirements that in today’s operations still rely heavily on human intervention.
The offshore energy industry relies on accurate ocean current measurements to reduce risk and optimize exploration, development, and production operations, especially in the Gulf of America where assets frequently get exposed to the effects of the Loop Current System (LCS). The current industry standard for LC surveys utilizes a data acquisition system deployed aboard offshore supply vessels (OSVs) of 200 feet or greater. Recent technological advancements have made it possible to deploy a comparable data collection payload from a purpose-built autonomous vessel. The first successful LC survey was conducted in August 2025 using Chance Maritime’s new 40-foot Uncrewed Surface Vessel (USV) designed for long endurance in extreme ocean conditions. The platform demonstrated five days of fully autonomous operation, collecting data comparable to measurements from traditional OSV-based surveys and demonstrating sufficient accuracy for operational use. This system offers a viable path toward improved real-time ocean monitoring and offshore decision support.
A new system for underwater mechanical application (patent pending) of underwater antifoulants will be dislosed. It incorporates Barnacle-Blocker, LLC's crayon-like wax based antifoulants into a hook & loop (compare to Velcro) disk that attaches to a mechanical polisher. The disks can be used on inderwater compatible polishing disks operated manually or by robots to coat propellors and other underwater surfaces with an antifoulant.
Through participation in the MATE ROV Competition, students develop and advance technical as well as employability skills – skills that are critical to supporting and furthering companies and organizations contributing to the Blue Economy. Further, via substantive interactions with professionals from the workplace who volunteer as judges, mentors, and technical support, students are exposed to potential careers, expand their awareness of job opportunities, and gain insights into career pathways.
Students as well as employers share that listing MATE on a resume moves job candidates to the top of the pile. To further elevate and increase that visibility and recognition of the role that the MATE ROV Competition plays expediting career preparedness and workforce development, MATE is partnering with Oceaneering International, other industry players, and educational institutions to validate and formalize the achievement of the knowledge and skills gained through participation in MATE.
This presentation will provide additional context as well as details on the work and progress to date.
Deploying AI on underwater and maritime platforms sounds straightforward until you're actually doing it. Teams run into the same friction points: integrating sensors from different vendors, building custom middleware, managing data pipelines, and trying to run inference on hardware with no reliable cloud connection. Most of that work has nothing to do with the problem they're actually trying to solve.
This talk covers how edge-native AI is changing that equation in working commercial systems today. Drawing on real deployments with VideoRay for automated underwater inspection, OceanAero for maritime threat detection on autonomous surface vessels, and WESMAR for intelligent commercial fishing sonar, we walk through what these integrations looked like, what broke, and what made them work. All three teams used NEPI (Numurus Edge Platform Interface) to skip rebuilding the sensor connectivity, edge inference, and data pipeline layers from scratch, freeing them to focus on the actual application.
Attendees will leave with a practical framework for evaluating edge AI for their own systems and a clear-eyed look at where the real integration challenges sit.
No sessions match your current filters.
Triton Systems, Inc. has developed an underwater hydraulic stud welder. It has been tested with US Navy divers at the Navy Experimental Diving Unit in Panama City, FL. It was developed under SBIR Phase I and II. Triton will give an overivew of the unit, the results from recent testing events, SBIR R&D experience developing a new technology, and its future plans for the technology.
While our industry continues to carry on best practices that have been handed down for decades, the upcoming generation of divers need to be taught not only skills but professionalism from the longstanding mentors among industry leaders. Best practices can only continue when they're adopted by the next generation, who also come with a new way of learning. By engaging a mentorship and growth mindset, companies that want to remain competitive as employers of new divers need to grow along with them in the perspective that the future of our industry needs.
Some underwater inspections demand more from the video record than simply proving a dive took place. For JF Brennan, clarity is essential to doing the work properly, documenting what was found, and delivering footage that can be reviewed and acted on after the dive is complete. This session will walk through two use cases where that need is especially clear: FERC-regulated hydropower dam inspections and nuclear inspections. In both environments, the limitations of analog-style underwater video become hard to ignore. When footage is unclear, difficult to retrieve, or harder to review, the burden carries forward into reporting, inspection acceptance, and next-step decisions. JF Brennan and Reach Systems will use these examples to explore the practical difference digital underwater video can make in demanding inspection workflows. In FERC-regulated hydropower dam inspections, footage may become part of engineering and regulatory review where the inspection record needs to hold up beyond the field team itself. In nuclear facilities, recurring inspection of high-value pumps leaves little room for unusable documentation, rejected inspections, or repeat effort caused by footage that is not clear or accessible enough the first time. For contractors, engineers, asset owners, and dive leaders, this session offers a concrete look at why digital clarity matters, where analog workflows fall short, and what stronger underwater video can change in the field and beyond.
Sound speed profiles derived from Argo float data underpin acoustic prediction, AUV mission planning, and GNSS-acoustic seafloor positioning — but no existing product tells you how well-constrained those profiles are at any given location and time. When an operator substitutes a climatological prior for an in-situ cast, they accept unquantified risk. If the underlying Argo coverage was sparse or stale for that region, there is currently no signal that the acoustic model or position estimate is degraded.
This presentation introduces an open-source Python library that fills that gap. The library performs spatiotemporal interpolation of Argo temperature and salinity profiles and delivers two outputs at every query point: a propagated uncertainty estimate that combines sensor precision, vertical interpolation error, and spatiotemporal support; and an observational support score W, a coverage indicator that is large where floats are dense and recent, and small where coverage is sparse. Both outputs are delivered at query time, alongside the T/S estimate itself.
Results are validated through replication of a published Bay of Bengal sound speed study. Interpolation-introduced uncertainty substantially exceeds sensor precision and is comparable in magnitude to observed surface temperature variability, confirming that coverage gaps produce errors large enough to matter operationally. A support-encoded visualization makes these gaps immediately legible: well-constrained regions appear vivid, sparse regions wash out.
The library is available at github.com/Calvinxc1/argo-data-interpolation and supports both EOS-80 and TEOS-10 sound speed formulations. The goal is a practitioner-facing tool: something an AUV operator or acoustic modeler can query against their mission area and get an honest answer about what the float network actually knows.
Commercial diving carries inherent risks including Delta-P, entanglement, contaminated water, equipment failure, decompression illness, and human factors. This presentation examines how risk manifests and is mitigated from three critical viewpoints: the diver (end user), the contractor (employer/operator), and the client/site owner.
From the diver’s perspective, the individual bears immediate physical exposure. Mitigation emphasizes personal accountability: maintaining medical fitness, actively participating in job hazard analyses and pre-dive briefings, exercising Stop Work Authority when conditions exceed safe limits, and adopting disciplined habits such as bailout readiness and accurate logging. A key principle is leaving personal risk tolerance at the door upon signing in — recreational judgments do not apply; operations must follow the company’s defined risk thresholds.
From the contractor’s perspective, the company defines and enforces acceptable risk levels. Responsibilities include assigning qualified personnel, conducting thorough risk assessments and dive plans, providing proper equipment and training, and maintaining a strong safety culture. Through onboarding, toolbox talks, and daily safety meetings, contractors must clearly communicate risk tolerance and ensure employees understand that personal shortcuts are unacceptable once on the job. Comprehensive documentation, including signed JHAs and dive logs, provides essential liability protection.
From the client/site owner’s perspective, risk is influenced through contractor selection, project timelines, and site information quality. Clients without in-house diving expertise can significantly reduce exposure by choosing ADCI audited contractors with proven safety records and adequate insurance. Providing complete hazard data upfront and allowing sufficient planning time further strengthens risk controls.
This presentation highlights how aligned perspectives, clear communication, and professional practices among the diver, contractor, and client create layered protection that enhances safety and reduces liability in commercial diving operations. Practical takeaways and a simple three-perspective checklist will be provided.
The traditional model for subsea validation is a primary friction point for the Blue Economy, characterized by high capital risk, lack of infrastructure and fragmented data/systems. This presentation introduces an emerging paradigm in maritime innovation: the persistent, instrumented subsea test range. By establishing a five-nautical-mile-square "experimental airspace" in the underwater domain, we solve the critical challenge of GPS-denied navigation and real-time telemetry. We will present on a real world facility at Plymouth Smart Sound in the UK as well as aspirations for the US and wider markets.
The core innovation lies in a distributed mesh of acoustic positioning and communication nodes that function as "seabed satellites”. This network enables seamless tracking, positioning, navigation and data transfer from subsea robotic platforms to a surface gateway (buoys, vessels, USVs), which utilize high-speed satellite broadband to reach a remote operations center. When integrated with real-time environmental sensors and digital twin management systems, the range creates a live situational picture that allows for the testing and validation of subsea vehicle behaviors such as AI/ML.
We will explore how this infrastructure model standardizes TRL progression for offshore energy, defense, and science. Attendees will learn how networked sensing can shift the industry from bespoke, high-cost prototypes to scalable, field proven and market ready autonomous systems. Innovation isn’t just about robots, its about data. This is a networked environment that allow them to fail fast, fail small and fail safely to learn faster!
With the currrent emphasis on renewable energy throughout the world, existing hydropower infrastructure is being called upon more than ever before. Many structures are in desperate need of repair, maintenance, retrofit, and upgrades to maintain/boost production and overall efficiency. Specifically, the higher head facilities tend to be in difficult to access locations well above sea level, which present unique challenges to maintain both dive safely and efficiency to complete the work.
The US Navy Revision 7 provides direction for conducting dives with enriched oxygen (Nitrox), incorporating surface decompression on oxygen (SurDO2), and adjustments for higher altitudes. However, combining all three dive methods can be challenging; as doing this isn’t clearly defined in the USN tables.
J.F. Brennan Company, Inc. (Brennan) had the opportunity to combine these dive methods on a 3-year project in the Wasatch Mountains of Utah. The project involved diving on a reservoir situated at over 5,400’, and water depths ranging from 55’ to 125’. Brennan, with support from various experts in the field, extrapolated dive profiles to execute the work in a safe and efficient manner; utilizing various breathing mediums, safety stops, and decompression tables to achieve success. We will share our combined experience, dive profile selection process, safety protocols , and successful results to better prepare divers for similar projects in the future.
Accurate, reliable heading is fundamental to marine and subsea navigation particularly in GNSS-denied environments. Existing solutions force a trade-off: optical gyros, such as Fibre Optic Gyros and Ring Laser Gyros, deliver high precision but are large, power-hungry, and expensive, while lower-cost alternatives, such as GNSS heading and magnetometers, are highly sensitive to signal vulnerabilities or environmental conditions.
This presentation introduces the first commercially available MEMS-based north-seeking gyrocompass, targeting a critical market gap. Using advanced MEMS technology and advanced algorithms, the system directly measures Earth’s rotation to determine true heading eliminating reliance on magnetic sensing or external aiding.
The SBG Systems gyrocompass achieves sub-degree heading accuracy with fast alignment, even while in motion. It does so with minimal SWaP-C (Size, Weight, Power and Cost) impact, operating at 3–5 W and weighing just 300–400 g. This is significantly smaller, lighter, and more efficient than traditional inertial systems such as optical or spinning-mass.
Rather than replacing survey-grade gyros, this technology expands access to true north-seeking capability. It enables reliable, always-available navigation for constrained platforms, including micro-AUVs, ROVs, USVs, and commercial vessels. MEMS gyrocompassing is a scalable, cost-effective solution poised to reshape heading systems for the next generation of autonomous marine operations.
The traditional view of decompression sickness (DCS) pathophysiology is that injuries occur due to bubbles formed from insoluble gas. However, the role of bubbles is obscure because asymptomatic blood-borne bubbles are often present. A growing body of evidence suggests that DCS is a systemic process that involves activation of white blood cells and so-called microparticles that carry inflammatory chemicals. A natural defense against the inflammatory microparticles is a protein called plasma gelsolin (pGSN). The level of pGSN in the blood stream drops as a consequence of diving and in animals, repletion of this protein can prevent DCS and also treat it subsequent to provocative diving. Human studies investigating the potential for human recombinant pGSN to prevent inflammatory responses to provocative diving are underway and this presentation will summarize the scientific basis and progress on this investigation.
ABSTRACT
El Guavio Hydroelectric Plant (1,260 MW), operated by Enel Colombia, faces an accelerated sedimentation process threatening the operability of its deep water intake, located approximately 135 m below the reservoir's mean level. Given the impossibility of constructing a new permanent intake in the short term, SKAVA Deep Solutions designed, fabricated and installed an innovative temporary solution: a perimetral protection screen composed of 24 prefabricated steel sheet-pile modules, installed entirely through saturation diving at great depth, in zero-visibility conditions and with ROV assistance.
The intervention increased the effective operational height of the intake structure by 7.8 m, extending the service life of the intake by approximately four additional years. The project was completed within the scheduled plant shutdown, with no disabling incidents and no environmental impact, establishing a milestone in high-altitude underwater engineering in Latin America.
Keywords: deep water intake, sedimentation, sheet piles, saturation diving, temporary rehabilitation, Guavio.
1. INTRODUCTION
Deep water intakes in hydroelectric plants constitute strategically critical infrastructure whose operation may be compromised by sedimentation processes that exceed original design projections. In the context of increasing climate variability, rates of solid material accumulation in high-altitude reservoirs tend to accelerate, prematurely reducing the service life of intake systems and increasing the risk of particulate matter entering the turbine train.
El Guavio Hydroelectric Plant, one of Colombia’s most powerful facilities with 1,260 MW of installed capacity, faces precisely this scenario. Its original intake was designed to withstand approximately 35 years of sediment accumulation; however, adverse climatic factors caused sedimentation rates significantly higher than projected, reducing the structure’s operational horizon.
Given the impossibility of constructing a permanent intake in an alternative location in the short term, an interim plan was activated with the objective of extending the operation of the existing intake for approximately four additional years. This paper describes the underwater engineering solution developed by SKAVA Deep Solutions, a company specializing in deep-water operations, which led the design, fabrication and installation of a perimetral protection screen under extreme conditions.
2. CONTEXT AND PROBLEM STATEMENT
2.1 Infrastructure Description
The deep water intake of Guavio Plant operates at approximately 135 m below the reservoir’s mean water level. The structure consists of concrete edges supporting a metallic grating cage that allows water flow to enter the pressurized conveyance system.
The original design provided for a service life of approximately 35 years against progressive sediment accumulation. The hydrostatic pressure at this depth exceeds 13.5 kg/cm², imposing severe constraints on both materials and intervention procedures.
2.2 Sediment Accumulation: The Critical Threat
The primary operational risk in high-altitude reservoirs lies in the progressive increase of sediment levels. Due to natural hydrodynamic processes and upstream erosion, the reservoir floor experiences a constant accumulation of solid material (sands, gravels and silts). This accumulation posed a critical threat of reaching the elevation of the intake tower’s suction screen, with potentially catastrophic consequences:
● Erosive damage to turbine blades: the abrasive material would act as an accelerated wear agent, drastically reducing equipment efficiency and service life.
● Obstruction of auxiliary systems: clogging of cooling ducts and control circuits.
● Instability of the national power supply: unscheduled shutdowns for emergency repairs would compromise the stability of the interconnected grid, with large-scale economic and social impact.
3. GENERAL CONCEPT
The objective of the interim plan was to allow additional sediment accumulation against the intake walls without allowing it to enter the turbine flow. To achieve this, the approach proposed blocking water passage through the vertical faces of the intake cage, allowing flow only through the top face.
In this way, the effective permissible sedimentation height was increased, temporarily extending operations while a permanent solution was developed elsewhere in the facility. The heightening structure had to be structurally robust against the hydrodynamic suction forces generated during full-load operation, and its installation had to be feasible at 130 m depth under near-zero visibility conditions.
4. OPTIMIZED DESIGN DEVELOPMENT
4.1 Propuesta Inicial del Client
Enel provided a basic engineering-level solution based on steel plates bolted directly to the existing screen. This alternative presented critical limitations that compromised both its constructability and its effectiveness:
● No sealing solution between the plates and the concrete.
● Incomplete sizing of fastening bolts.
● Undefined overlaps at structural corners.
● Lack of guaranteed watertightness.
● High degree of direct human intervention, not feasible at 130 m depth under zero-visibility conditions.
4.2 SKAVA's Proposed Solution: Sheet-Pile Modules
SKAVA’s first task was to review the constructability of the basic design and propose an alternative that would guarantee watertightness and ease of installation, reducing human exposure to the absolute minimum.
After evaluating multiple alternatives, a solution based on prefabricated high-strength steel sheet-pile modules was adopted. A total of 24 modules were designed, manufactured entirely in steel and protected with anti-corrosion coating systems certified for long-term submerged environments.
The interlocking system inherent to the sheet piles enabled sequential module engagement, achieving a complete seal around the intake perimeter. The core elements of the optimized design were:
● Prefabricated and stiffened modules: welded with stiffening beams, fully assembled and dimensionally validated in the workshop prior to transport.
● Specialized bottom seal: each module incorporated a perimetral bottom seal to ensure waterproofing at the interface with the concrete structure.
● Bolted shear connections: designed to ensure structural load transfer between adjacent modules and resist suction forces during full-load operation.
● Blind-assembly design: male-female interfaces and high-security bolts enabling precise fit without direct visual contact.
For model validation, advanced computational fluid dynamics analyses were conducted to ensure the structure could withstand not only static hydrostatic pressure exceeding 13 kg/cm², but also the dynamic suction forces generated when the plant operates at full load (1,260 MW).
5. DEPLOYMENT LOGISTICS
The mobilization of resources for this project entailed a continental-scale logistics operation. The saturation diving system was transported from Mexico in a multimodal operation (maritime and overland) under strict international industrial safety standards.
Once in Colombian territory, more than 1,000 metric tons of equipment crossed the complex Andean road network. A fleet of 89 trucks transported everything from heavy steel structures to delicate hyperbaric life-support systems. Breathing gas management represented another major challenge: at 130 m depth, atmospheric air becomes toxic, requiring the preparation and transport of 4,500 m³ of helium and 1,000 m³ of oxygen for the formulation of the Heliox mixture used in saturation operations.
Construction operations were organized into three simultaneous work fronts:
● External logistics front: support operations in Bogotá, Cartagena de Indias, the reservoir shoreline, and other staging and coordination points.
● Main floating platform: a modular structure of 18 interconnected flexiboats, covering approximately 700 m², anchored at four points directly above the intake. It housed the 100-ton main crane, the ROV control station, and the saturation module "El Dorado".
● Direct underwater front: execution of works at the intake using saturation divers at 130 m depth.
6. OPERATIONAL EXECUTION: INSTALLATION UNDER EXTREME CONDITIONS
6.1 Saturation Diving
The most critical activity of the project was carried out using saturation diving technology. This procedure allows the divers’ bodies to equilibrate with the gas pressure at the working depth, eliminating the need for daily decompressions and enabling extended periods of effective bottom work.
The divers remained under saturation throughout the approximately 30-day campaign inside the "El Dorado" module, descending via a diving bell. Each dive deployed two divers, though only one performed active work. Operations were organized in 8-hour shifts with a rotating team of six divers, ensuring uninterrupted operational continuity.
6.2 Assembly Under Zero-Visibility Conditions
At 130 meters depth and in zero-visibility conditions, a diving team successfully performed a tactical assembly working entirely by touch. Mission success depended on an advanced technological network that included:
- Continuous communication: linking the surface supervisor, the diving bell, and the diver.
- Digital visualization: high-resolution sonar systems monitoring the area in real time.
- Robotic assistance: an ROV was used to position and deliver each module with exact precision prior to final manual adjustment.
6.3 Lifting Engineering and Millimetric Positioning
The lowering of the heavy modules was carried out using high-capacity cranes integrated into the floating platform. Rigorous Lifting Plans were implemented, accounting for submarine current dynamics and the effect of pressure on component stability.
Synchronization between the surface operator and the underwater team enabled control of the "pendulum effect" of loads at depth, allowing each component to engage precisely with its structural guides. This procedure was repeated systematically until all 24 modules were installed, after which the bolted shear connections were fitted and the assembly was verified through a final ROV survey.
6.4 Safety Management and Operational Continuity
Operations were sustained continuously for more than 30 days. Logistical support was reinforced by a fleet of support vessels managing the constant flow of supplies, personnel and materials. The physical well-being of the divers was overseen by a specialized medical team and life-support technicians, who provided uninterrupted supervision of saturation chamber conditions, managing gas mixtures and decompression procedures in accordance with international standards.
The project was executed by 140 specialized professionals from Chile, Colombia, Brazil and Mexico. The technical expertise of the team, complemented by constant on-site supervision, enabled the completion of operations with zero disabling incidents and no environmental impact on the reservoir ecosystem.
7. RESULTS ACHIEVED
The implemented temporary solution delivered the following quantifiable results:
● A 7.8 m increase in the operational height of the intake structure, enabling greater sediment accumulation without entry into the turbine flow.
● Extension of the intake’s service life by approximately three additional years, providing the time margin required for the development of the permanent intake solution.
● Execution completed within the scheduled plant shutdown, confirming the constructability of the methodology under extreme conditions.
● Zero disabling accidents and zero environmental impacts recorded throughout the entire campaign.
8. LESSONS LEARNED
The execution of the temporary heightening at Guavio yielded high-value lessons for future interventions in deep hydraulic infrastructure:
● Constructability as the primary design criterion: in works at great depths and under zero-visibility conditions, success depends on engineering conceived from the earliest stages with assembly constraints, logistics and minimization of human exposure in mind.
● Modular approach to risk minimization: the prefabricated modular design significantly reduced the need for direct human intervention, requiring only one active diver per installation operation.
● ROV-diver integration as a standard methodology: the combination of remotely operated vehicles for positioning and geometric control with saturation divers for fitting and fastening maneuvers proved decisive for the precision and safety of the installation.
● Pre-installation workshop validation: the complete pre-assembly of all modules before transport to site prevented dimensional interferences during underwater installation, saving critical dive time.
● Gas management in high-altitude logistics: advance planning of Heliox mixture supply at industrial-scale volumes is essential to ensure operational continuity in projects of this magnitude.
9. CONCLUSIONS
The temporary heightening of the deep water intake at El Guavio Hydroelectric Plant constitutes a singular case in Latin American underwater engineering. SKAVA demonstrated that it is possible to design, fabricate and install highly complex structures at extreme depths, under zero-visibility conditions and to world-class safety standards.
The solution based on prefabricated sheet-pile modules, optimized for remote installation with minimal direct human intervention, overcame the limitations of the original basic design and delivered a structure with validated hydraulic, structural and watertightness performance. The effective integration of saturation diving and ROV as complementary tools made the decisive difference in the feasibility and safety of execution.
Beyond the immediate result, this project provides a replicable methodological model for the temporary rehabilitation of hydraulic infrastructure affected by accelerated sedimentation in deep-water contexts, contributing to the energy resilience of large-scale hydroelectric systems across Latin America and the world.
Kongsberg’s Listen is a passive electromagnetic sensor system designed for measuring electric and magnetic fields in seawater and optimized for integration on HUGIN AUVs. When installed on HUGIN, Listen uses hull‑flush‑mounted electrodes arranged into eight electrode pairs to reconstruct the full three‑dimensional electric field, combined with magnetometers that provide complementary magnetic measurements. This configuration enables low‑noise, repeatable data acquisition well suited to long‑range AUV missions.
Listen supports contactless cathodic protection (CP) inspection by exploiting the electric fields generated by active CP systems. A HUGIN AUV equipped with Listen can survey pipelines at typical altitudes of 5–10 m and speeds of 3–4 knots, continuously measuring the 3D electric field without physical contact. From these measurements, anode output currents, return currents into the structure, and anode material consumption rates can be estimated, enabling assessment of CP performance, coating condition, and remaining lifetime. The electromagnetic data can be integrated with navigation, camera, and multibeam echosounder data to deliver decision‑ready integrity information with high productivity and reduced operational risk.
Beyond CP inspection, Listen enables buried power cable detection, positioning, and burial‑depth estimation. Sea trials with the Listen receiver system deployed on a Hugin Superior AUV demonstrated high signal‑to‑noise electric and magnetic field measurements at the 50 Hz powerline frequency across multiple passes and altitudes. The results showed reliable cable detection at altitudes up to 20 m and burial‑depth estimation using combined electric‑ and magnetic‑field analysis, highlighting the value of multi‑field sensing compared to magnetic‑only approaches.
Ensuring the long-term integrity of subsea pipelines and seafloor assets is one of the most critical challenges in offshore energy operations. Traditional cathodic protection (CP) surveys often rely on intrusive methods or limited data acquisition, resulting in partial insights into corrosion risk and system performance. Ocean Floor Geophysics’ (OFG) patented integrated Cathodic Protection (iCP) technology represents a step-change in subsea asset integrity management—delivering non-intrusive, high-resolution, and spatially continuous assessments of cathodically protected systems.
The iCP system employs an innovative EMF sensing approach to detect and map the electrical and magnetic fields associated with CP currents, without requiring physical contact with the asset. This capability enables accurate characterization of CP performance of pipelines and subsea assets. By eliminating the need for direct electrical contact, iCP minimizes operational risk, reduces survey time, and allows for assessments over extensive pipeline sections and complex infrastructure.
OFG’s iCP technology can be deployed via Autonomous Underwater Vehicles (AUVs) or Remotely Operated Vehicles (ROVs), offering flexible and scalable inspection strategies. During deployment, the system collects synchronized, high-density electromagnetic data, which are processed to generate detailed maps of current distribution and potential gradients. The result is a comprehensive and quantitative view of CP system health—providing engineers with the actionable intelligence required to evaluate system adequacy, detect anomalies, and plan proactive maintenance interventions.
The insights derived from iCP measurements extend beyond basic compliance verification. By integrating these data into advanced modeling workflows, asset integrity teams can predict coating degradation, estimate remaining CP life, and design optimized retrofit or life-extension programs based on measured, rather than assumed, performance. The technology thus bridges the gap between inspection data and engineering decision-making—supporting more sustainable, data-driven management of subsea assets throughout their operational lifecycle.
In this presentation, Ocean Floor Geophysics will showcase field results from recent iCP deployments on active subsea pipelines and production assets, illustrating the system’s ability to deliver unparalleled resolution and interpretive power. The discussion will highlight how non-intrusive CP monitoring transforms both the understanding and visualization of cathodic protection systems, setting a new benchmark for integrity assessment in the offshore sector.
Deeper dive into HSE key perfomance indicators. Discussion beyond common leading and lagging indicators. How many exposure man hours between high potenital events. Cost of HSE per exposure man hour. HSE competncy assessmnts. Leadership competency assesments.
The complex circulation of the Gulf of America, driven by the Loop Current (LC), Loop Current Eddies (LCEs), and cyclonic eddies (CEs), poses significant risks to offshore operations. Accurate identification of the location and intensity of these features is critical for defining safe operational windows but requires integration of diverse observational datasets.
This paper presents a frontal detection methodology in which the boundaries of LC/LCE features are estimated by the position of the 1.5‑knot isotach. The resulting fronts are used to characterize feature location and current intensity and validate numerical model output. The approach has been evaluated extensively since 1984 and is widely regarded as representative of ground truth for the placement of major oceanographic features in the region.
This session will provide and overview of what is legally required of commercial diving contractors and their divers.
No sessions match your current filters.
The 2023 Titan accident exposed significant gaps and inconsistencies in the international oversight of submersibles, placing lives at risk and undermining public confidence in the industry. In response, the MTS Submarine Committee and the World Submarine Organization (WSO) are working toward a more effective international governance framework for identifying submersibles and overseeing their operation, with the long-term objective of harmonization through the International Maritime Organization (IMO).
This presentation will provide an overview of the current state of the civilian submarine industry and examine the findings and recommendations arising from investigations by the U.S. Coast Guard, the U.S. National Transportation Safety Board, and the Transportation Safety Board of Canada. It will also report on the WSO Annual Flag State Meeting, held in Hamburg on September 15–16, 2026, where maritime and port authorities from approximately 15 countries will discuss a practical framework for improving submersible identification and regulatory oversight while balancing differing national requirements with the need for international consistency.
This presentation covers Commercial Diving and Mental Health as it relates to:
It does not cover Cliynical Phycology definitions of Mental Health.
It is currently a 40-45 min presentation. It could be trimmed if needed.
I will be attending the IOGP DOSC and IDIF all day meetings so if chosen it would need to be scheduled for the off day which I think will be Friday the 4th.
The underwater exploration company OceanGate publicly changed its procedures to reject established engineering codes and standards. They publicized they were going to innovate “like NASA” by developing a novel carbon fiber composite hull for its third submersible, the TITAN. The TITAN’s loss at sea with five people aboard in June 2023 captured worldwide media attention, which subsequently impacted the resulting investigations. This was the first loss of a non-military submersible in over 50 years and the first to be subject to a Marine Board of Investigation. The joint US Coast Guard/National Transportation Safety Board investigation brought much of the investigation process into the public, including the public hearings in 2024 and the publishing of the separate reports and findings of the USCG and NTSB in 2025. Kemper Engineering Services was the only non-governmental organization that was part of the official investigation. This presentation will be a summary of our findings, including the detailed failure analysis that indicates a second hull delamination between a 1-inch cured section is the most likely root cause of the implosion. We will also present our finding regarding design methods, simulation methods, acrylic window design, and air supply.
No sessions match your current filters.